LiDAR Based Object Mapping and Identification Rover
An autonomous rover for mapping and object identification, aimed at space debris tracking and warehouse management.
- Dates
- March 2022 to September 2022
- Stack
- Python, CNN, ROS, SLAM, Raspberry Pi, Keras
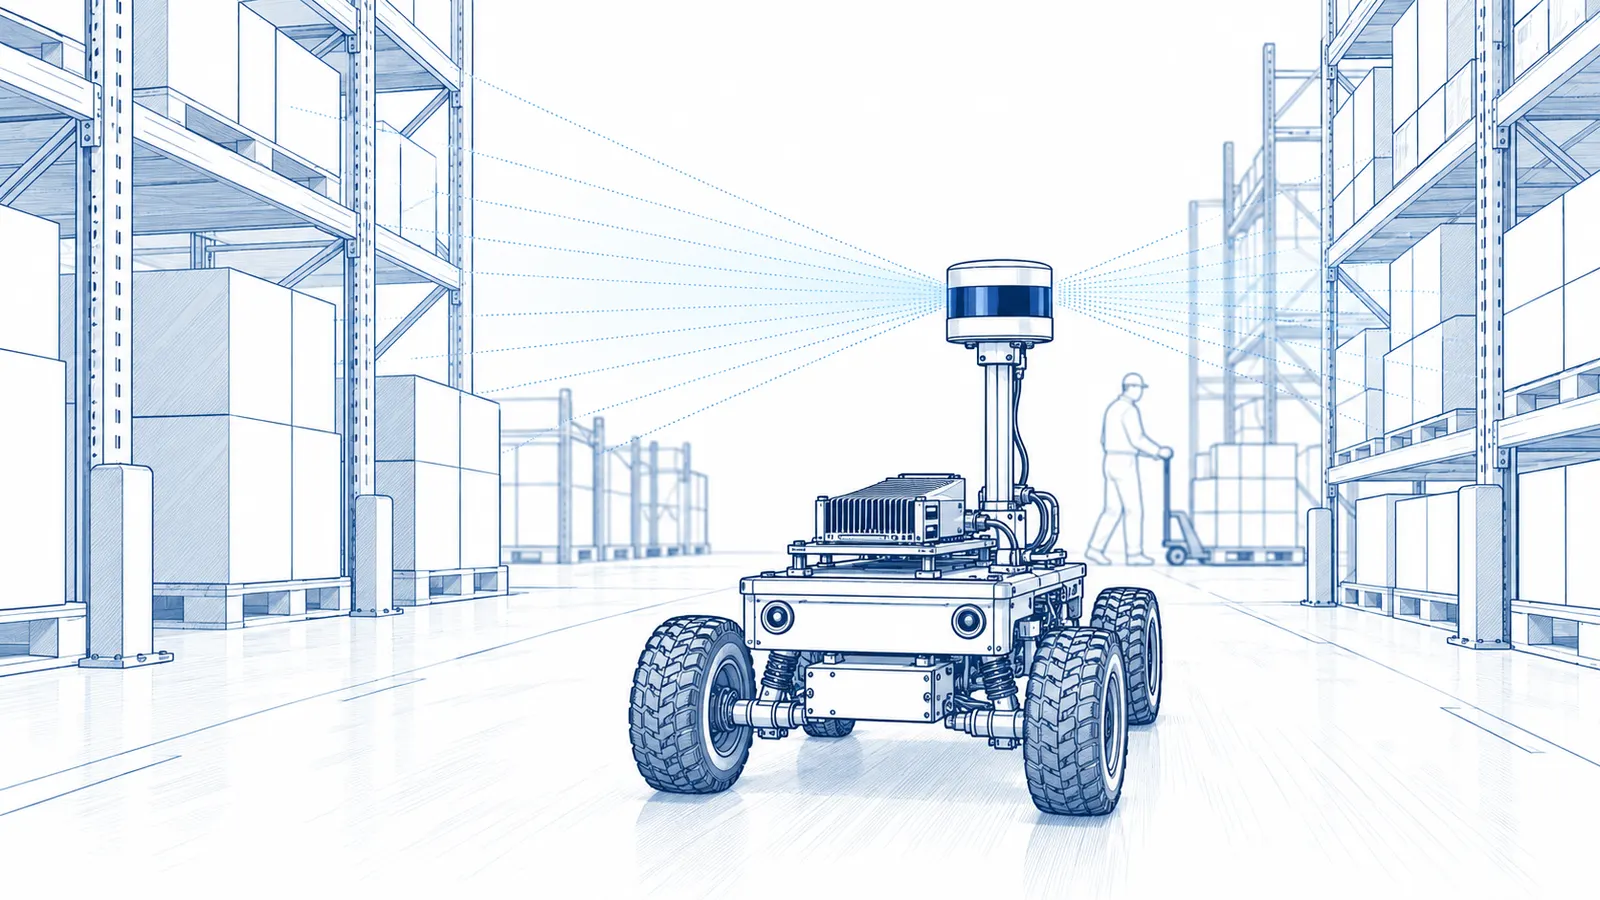
An autonomous rover built around LiDAR mapping and convolutional object identification, with SLAM for localisation. The two application cases explored were tracking space debris and warehouse management, which share a problem: identifying and keeping track of objects in a space you are simultaneously mapping.