MoonBot: Modular and On-Demand Reconfigurable Robot Toward Moon Base Construction
IEEE Transactions on Field Robotics (T-FR)
doi:10.1109/TFR.2025.3624346arXiv preprint
* Equal authorship.
My research lies at the intersection of space robotics and artificial intelligence.
Space is where the constraints bite: terrain nobody has surveyed, lighting with almost no usable shadow gradient, and no chance of a person walking over to help. The work falls into three directions, and most of it has been taken out of the lab into terrain chosen to stand in for the Moon.
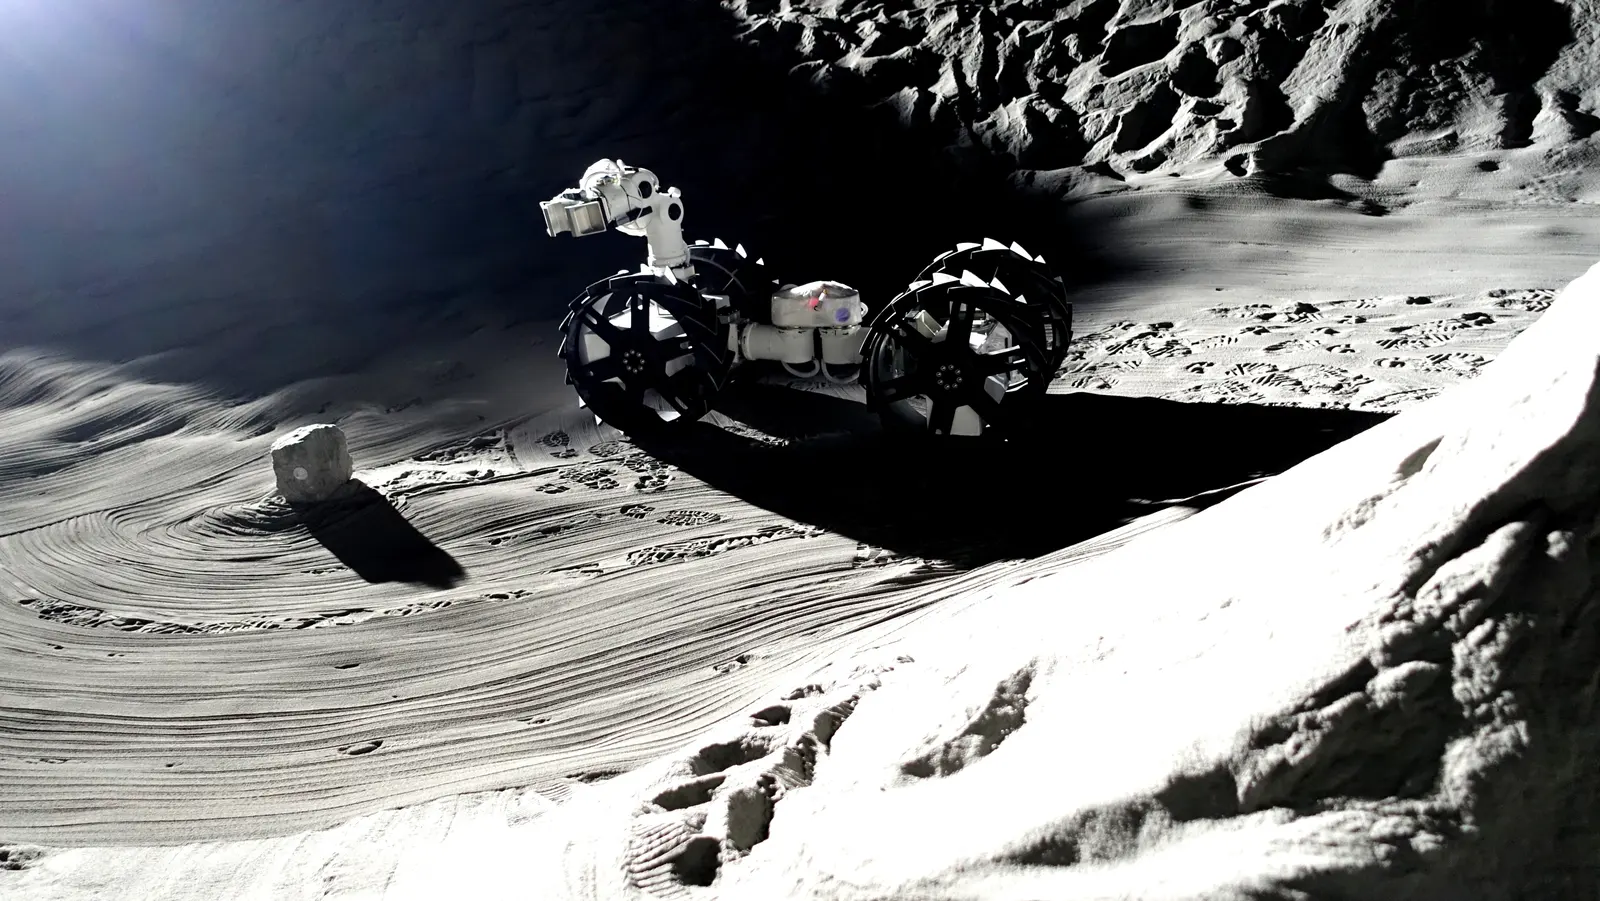
Doctoral work, Space Robotics Lab, Tohoku University
One set of limbs, wheels and tools that reconfigures on demand into whichever machine a lunar construction task needs.
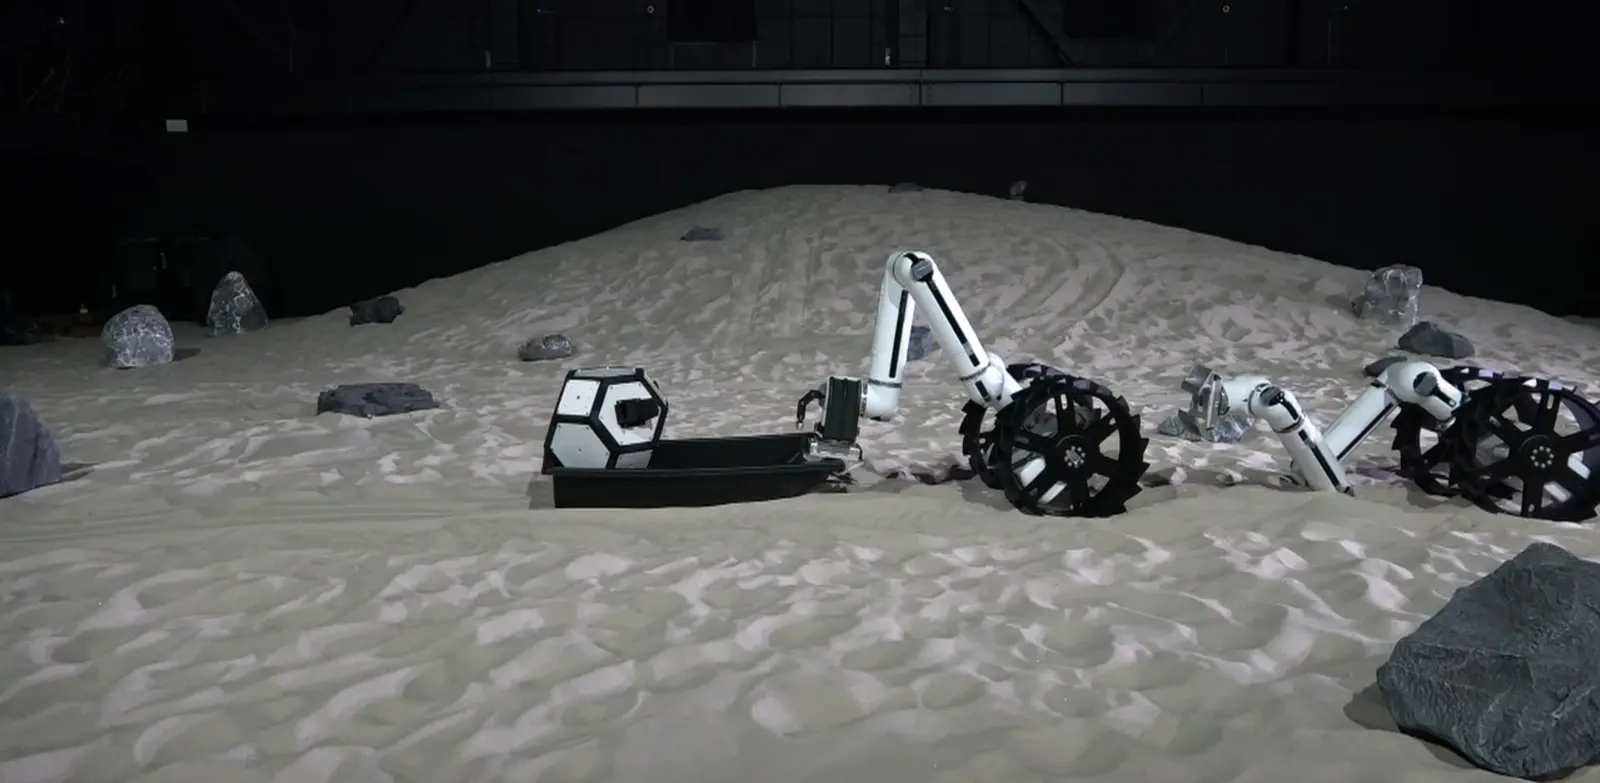
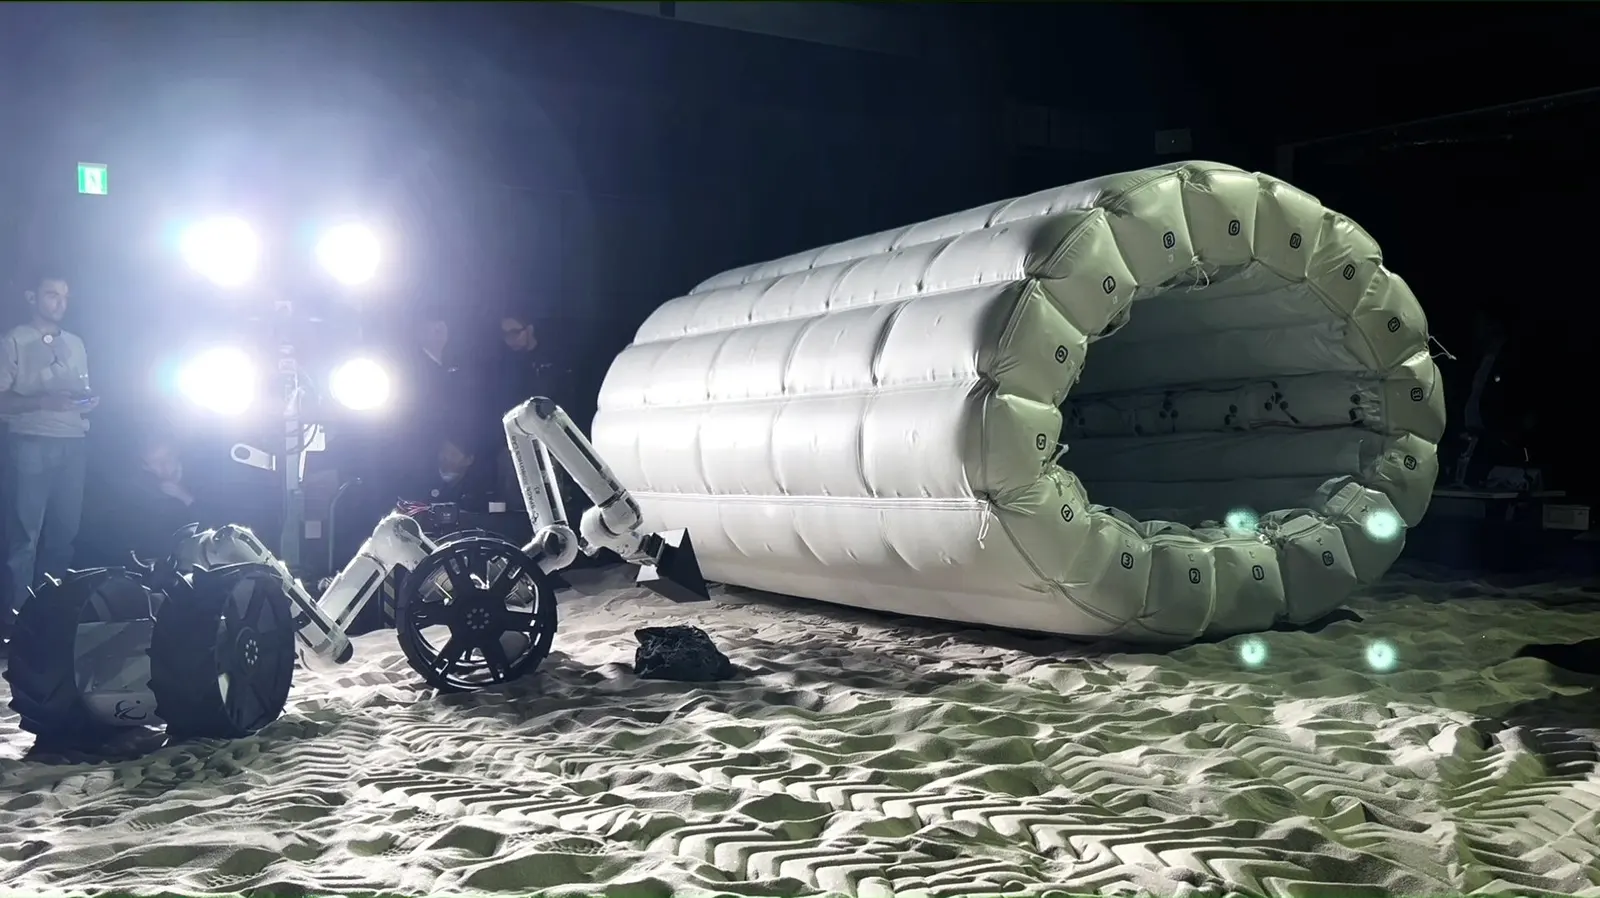
IEEE Transactions on Field Robotics (T-FR)
doi:10.1109/TFR.2025.3624346arXiv preprint
* Equal authorship.
IEEE International Conference on Automation Science and Engineering (CASE)
IEEE International Conference on Space Robotics (iSpaRo)
doi:10.1109/ISPARO66239.2025.11436148arXiv preprintVideo
Best Paper Award in Planetary Robotics, IEEE iSpaRo 2025, Sendai, Japan
The Dynamic Legged Systems lab at Istituto Italiano di Tecnologia (IIT) in Genova, where I work now; the Space Robotics Lab at Tohoku University, where MoonBot was built; the JAXA Space Exploration Test Field, where it was field tested; and the groups before them.Everyone the work has been done with.