Legged locomotion for space
Current work
How does a legged robot keep walking on terrain that no one has surveyed, with no chance of rescue?
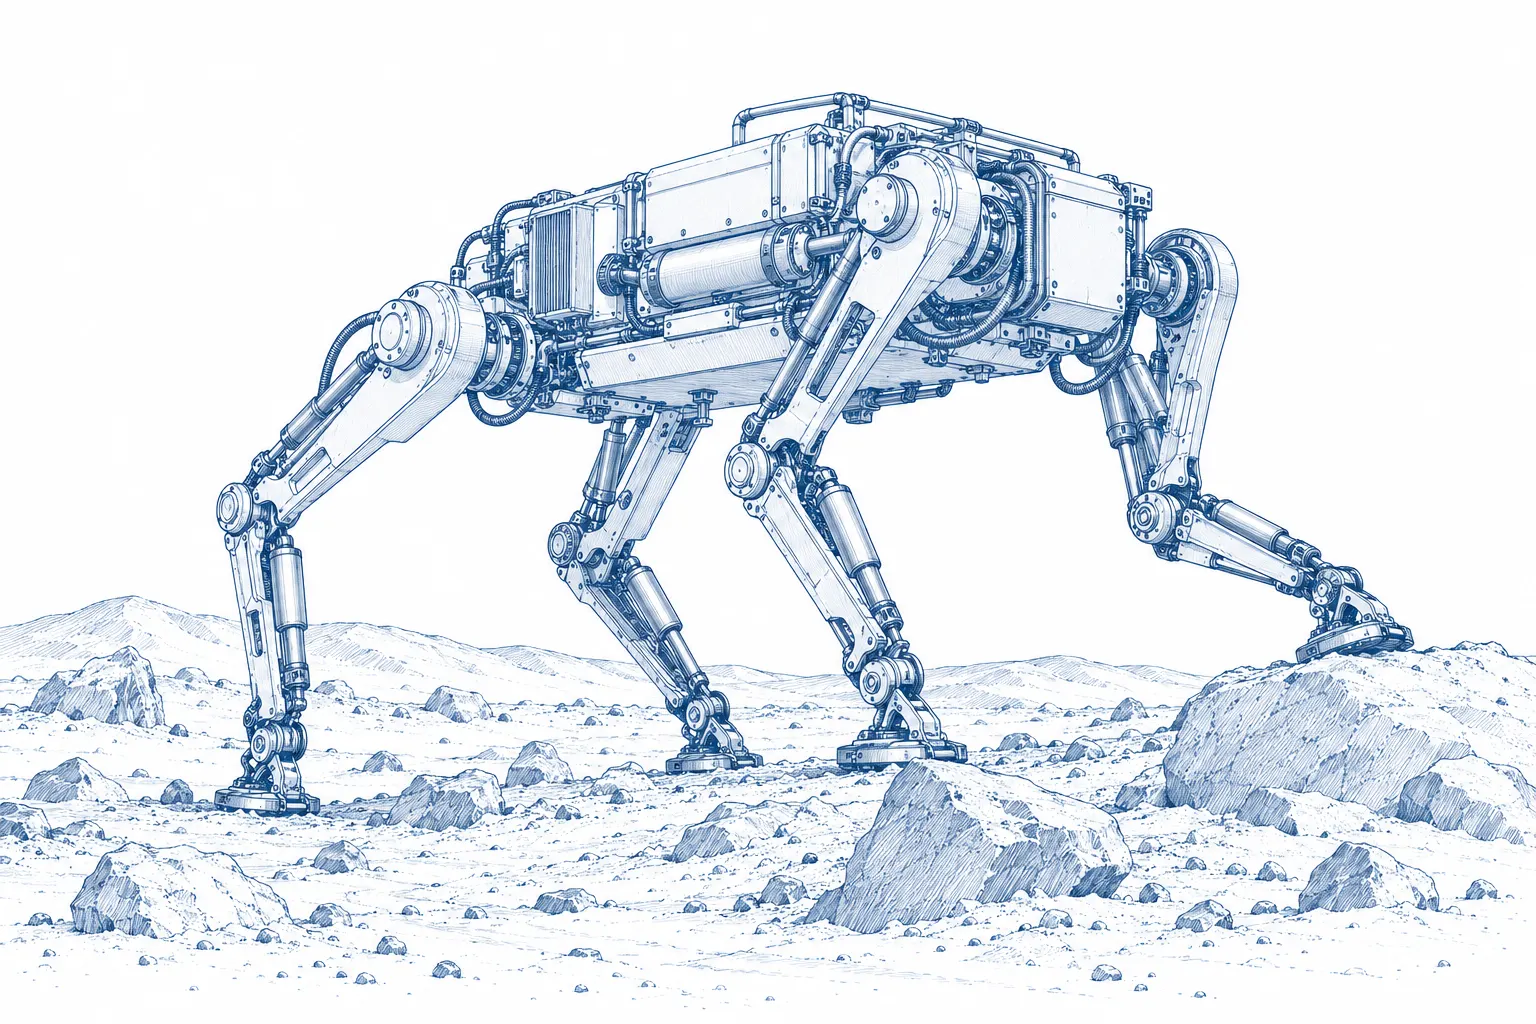
Wheels are a reasonable choice on graded terrain. Most of the lunar surface is not graded. Legs can step over and around what wheels have to drive through, but that flexibility only helps if the controller can decide where to put a foot on ground it has never seen, under lighting that gives almost no usable shadow gradient.
This is the work I do now in the Dynamic Legged Systems lab at Istituto Italiano di Tecnologia (IIT) in Genova, with Claudio Semini, under the ALTEC project. It is mostly reinforcement learning trained on GPU at scale, and then the harder half: the sim-to-real transfer pipeline that decides whether a policy which looks excellent in Isaac Lab still works once it is driving real actuators.