MoonBot: Modular and On-Demand Reconfigurable Robot Toward Moon Base Construction
IEEE Transactions on Field Robotics (T-FR)
doi:10.1109/TFR.2025.3624346arXiv preprint
* Equal authorship.
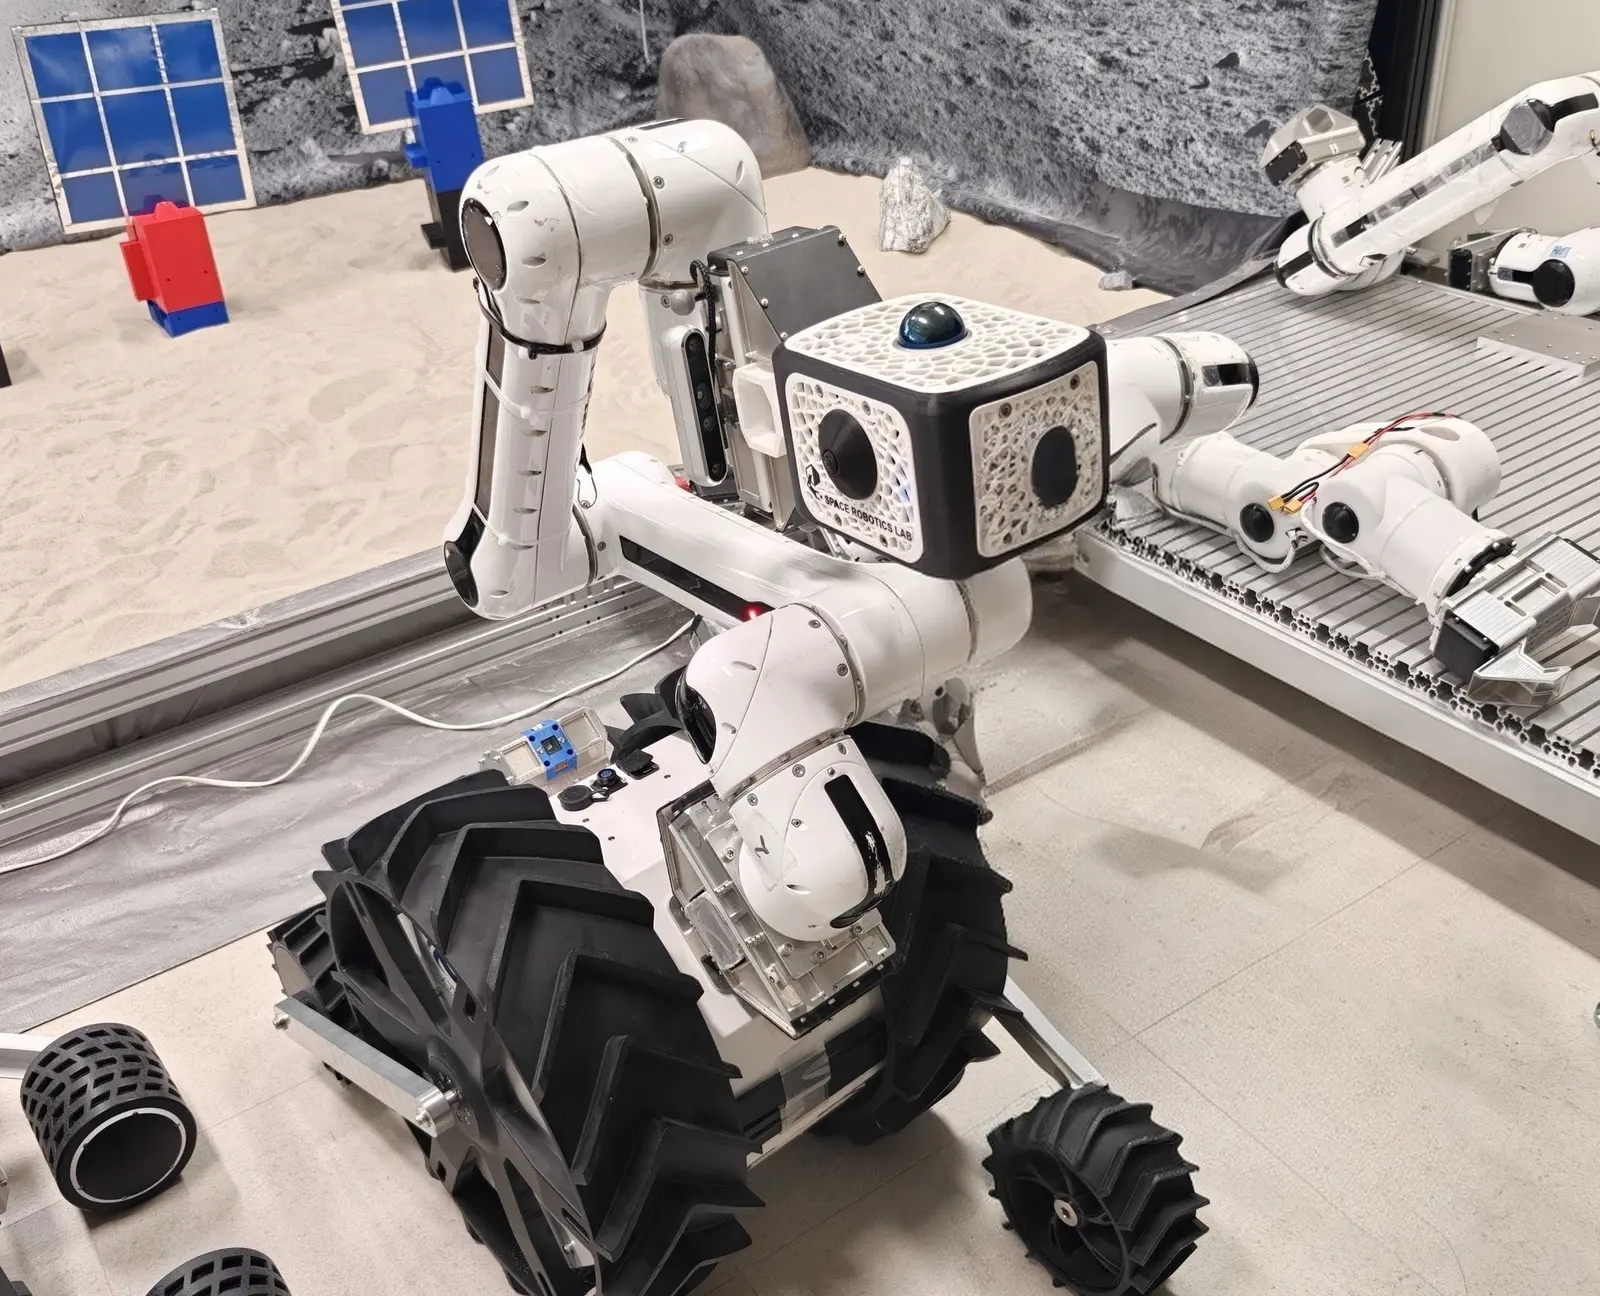
One set of limbs, wheels and tools that reconfigures on demand into whichever machine a lunar construction task needs.
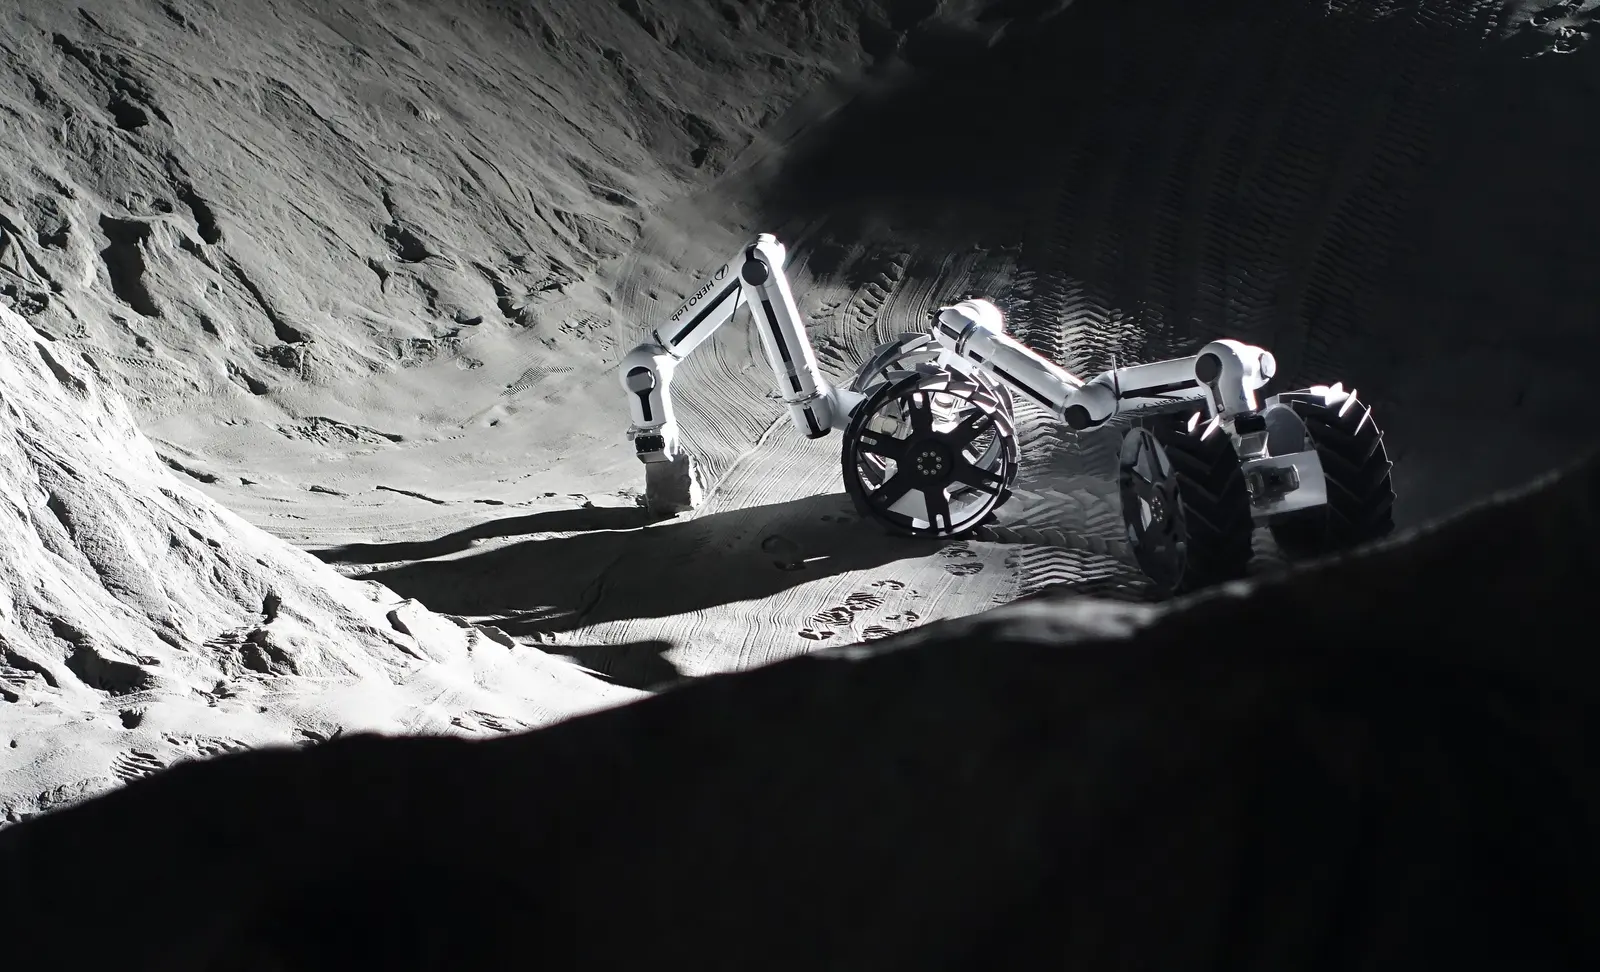
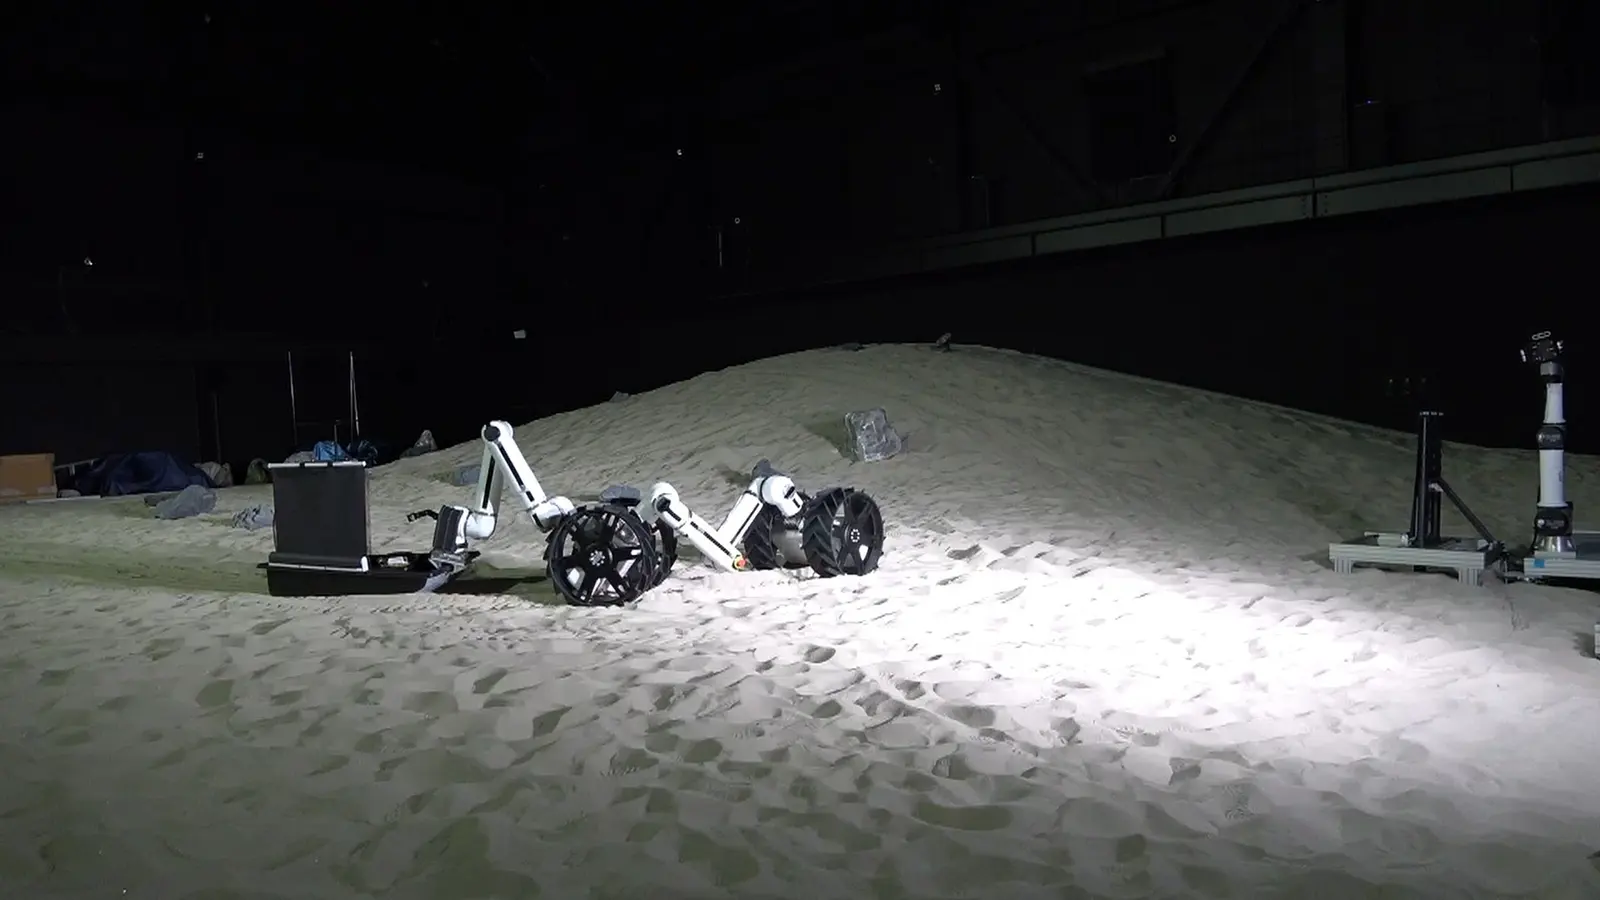
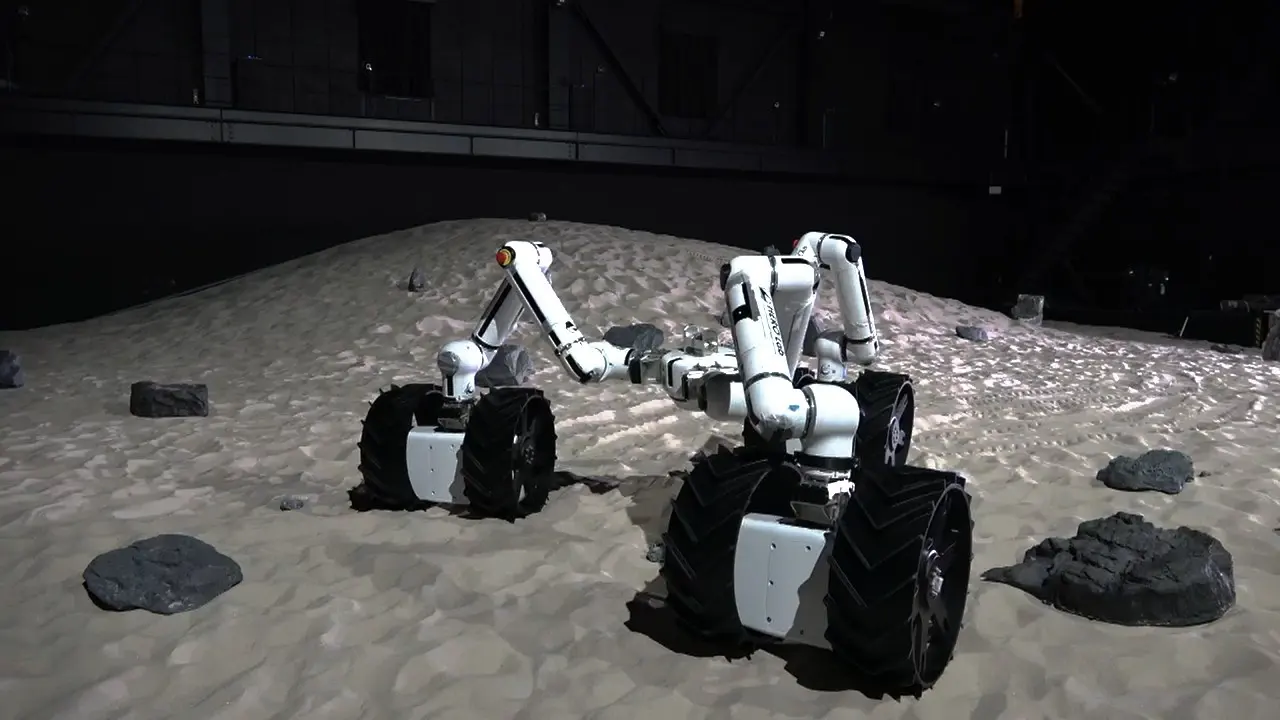
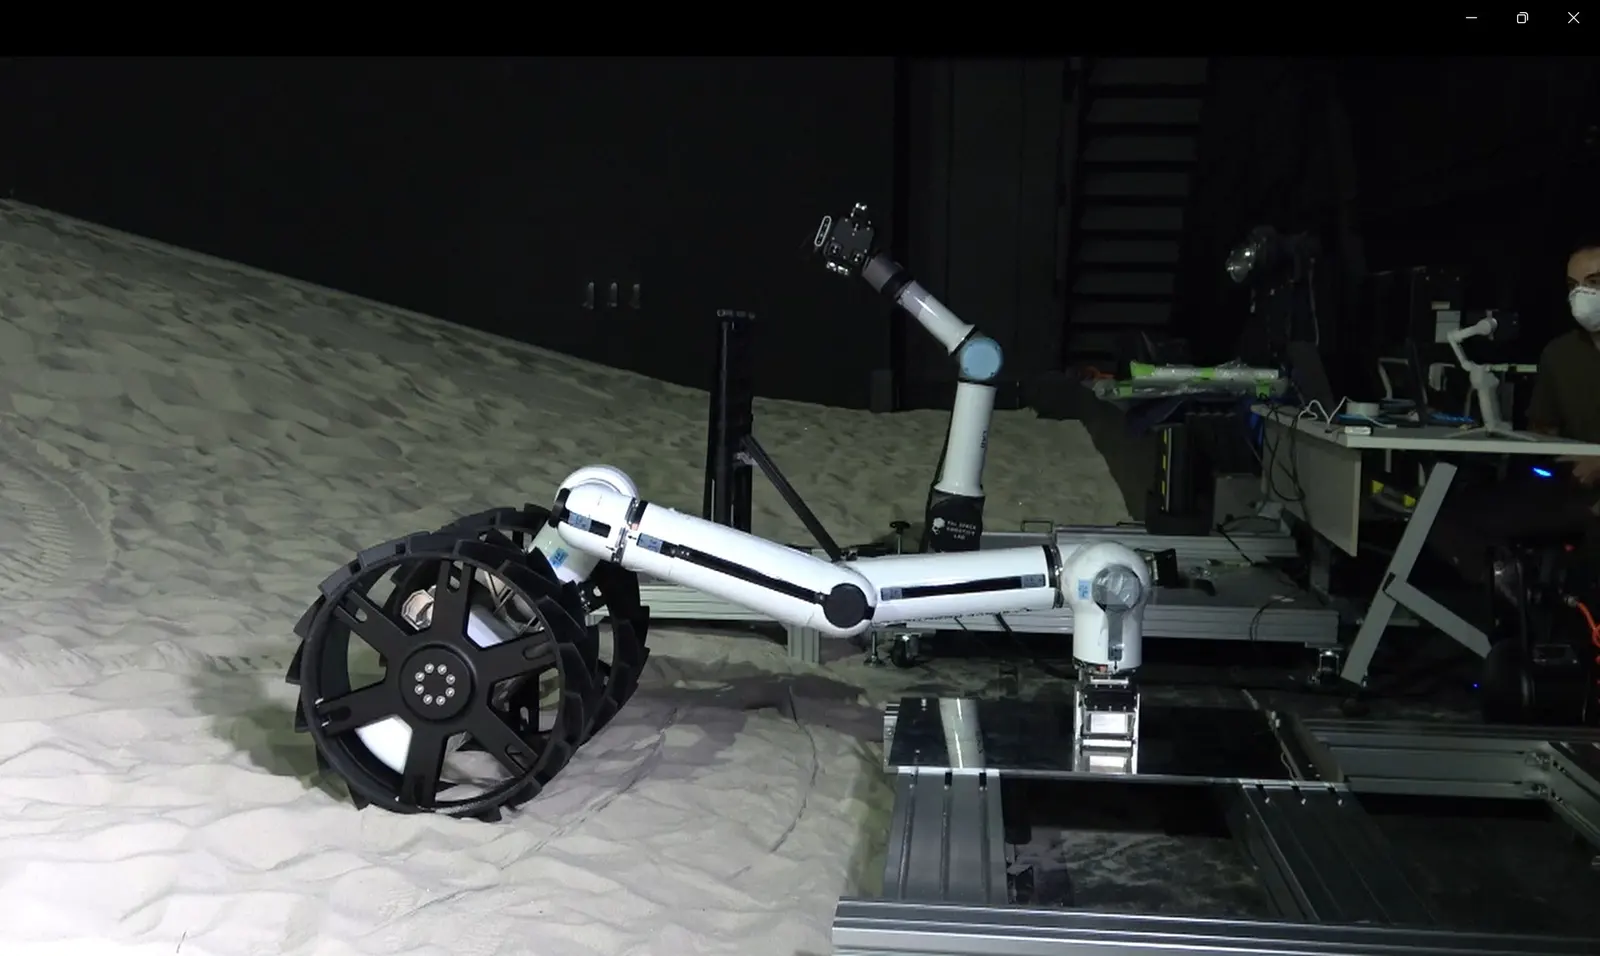
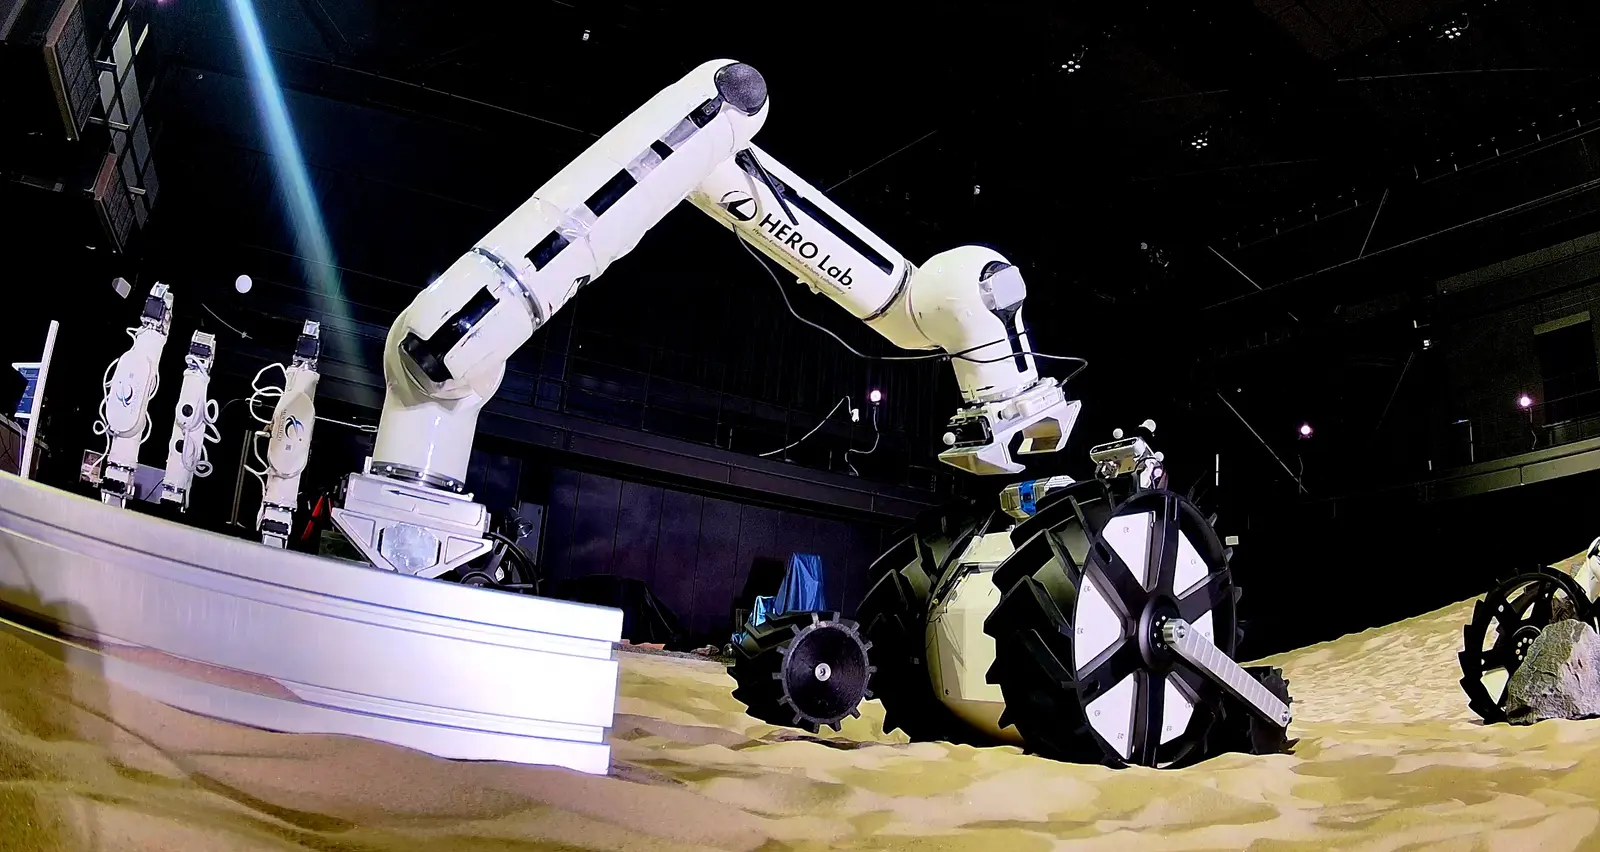
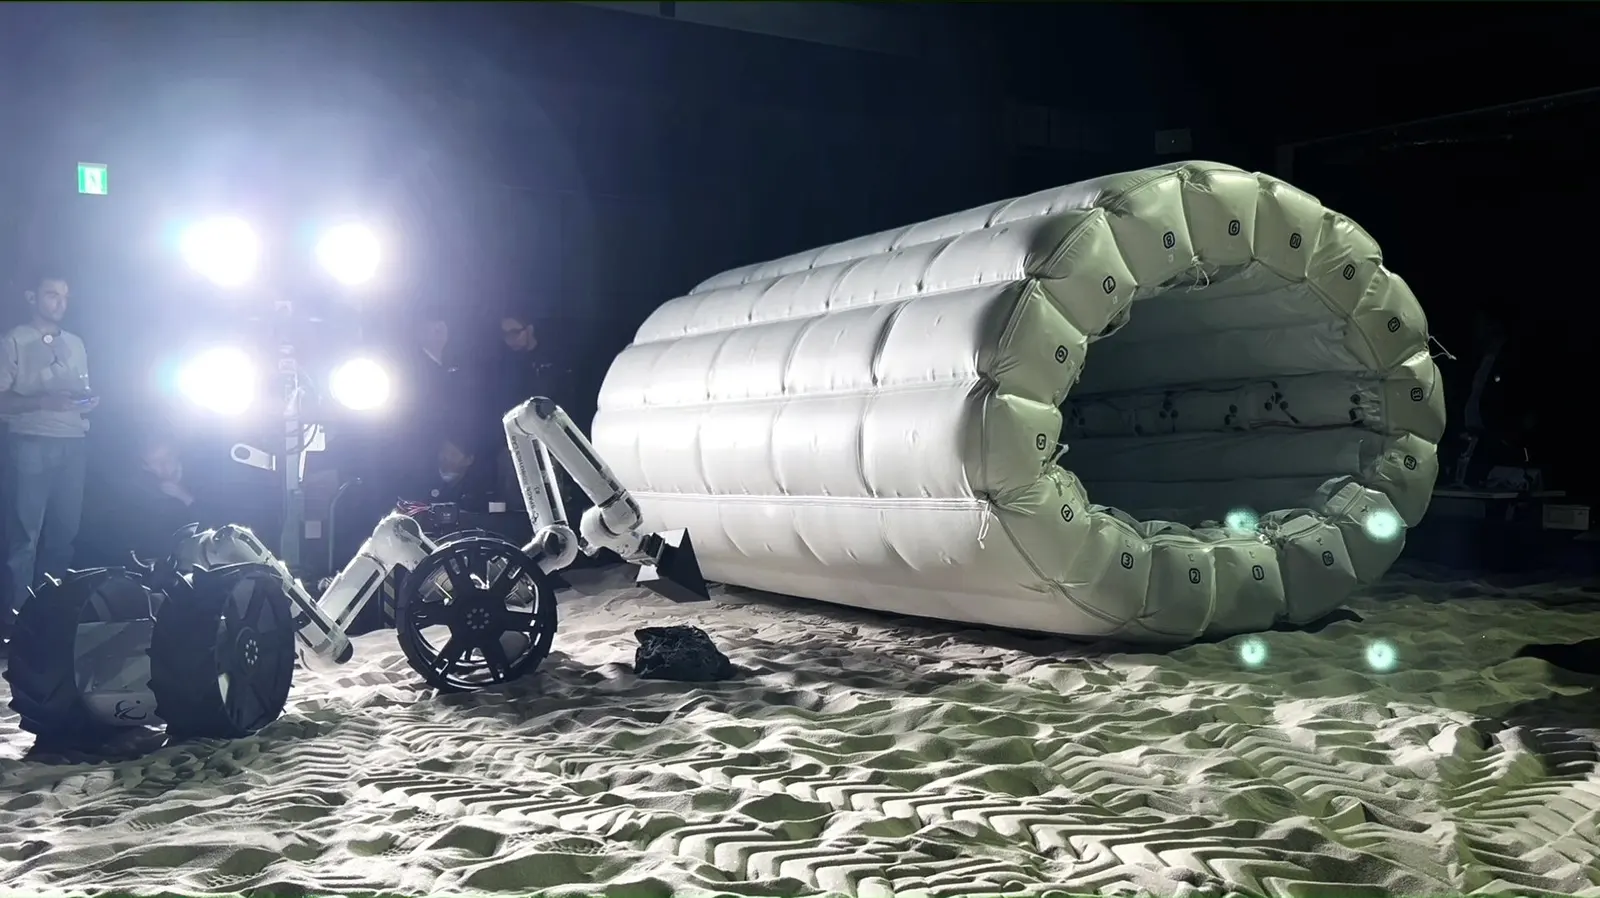
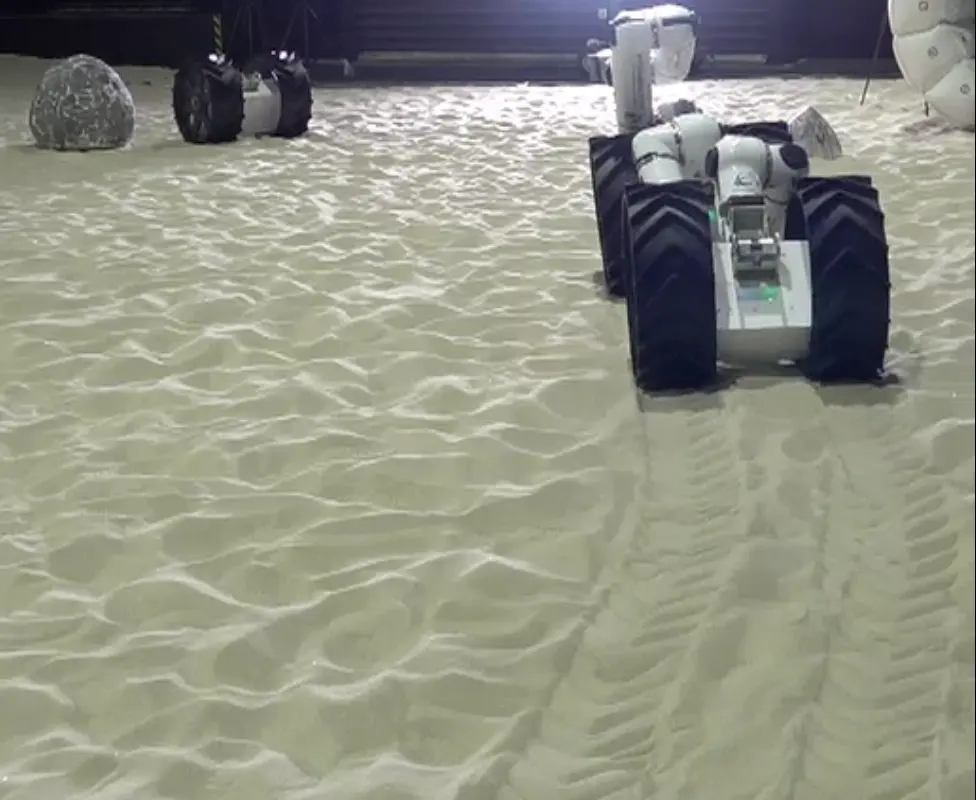
Every kilogram landed on the Moon is expensive, so a construction site there cannot afford a separate machine for every job. MoonBot answers that with modularity: limbs, wheels and tools that connect on demand, so the same hardware becomes a manipulator, a vehicle, a walker or an excavator, within the mass limits of a lunar payload.
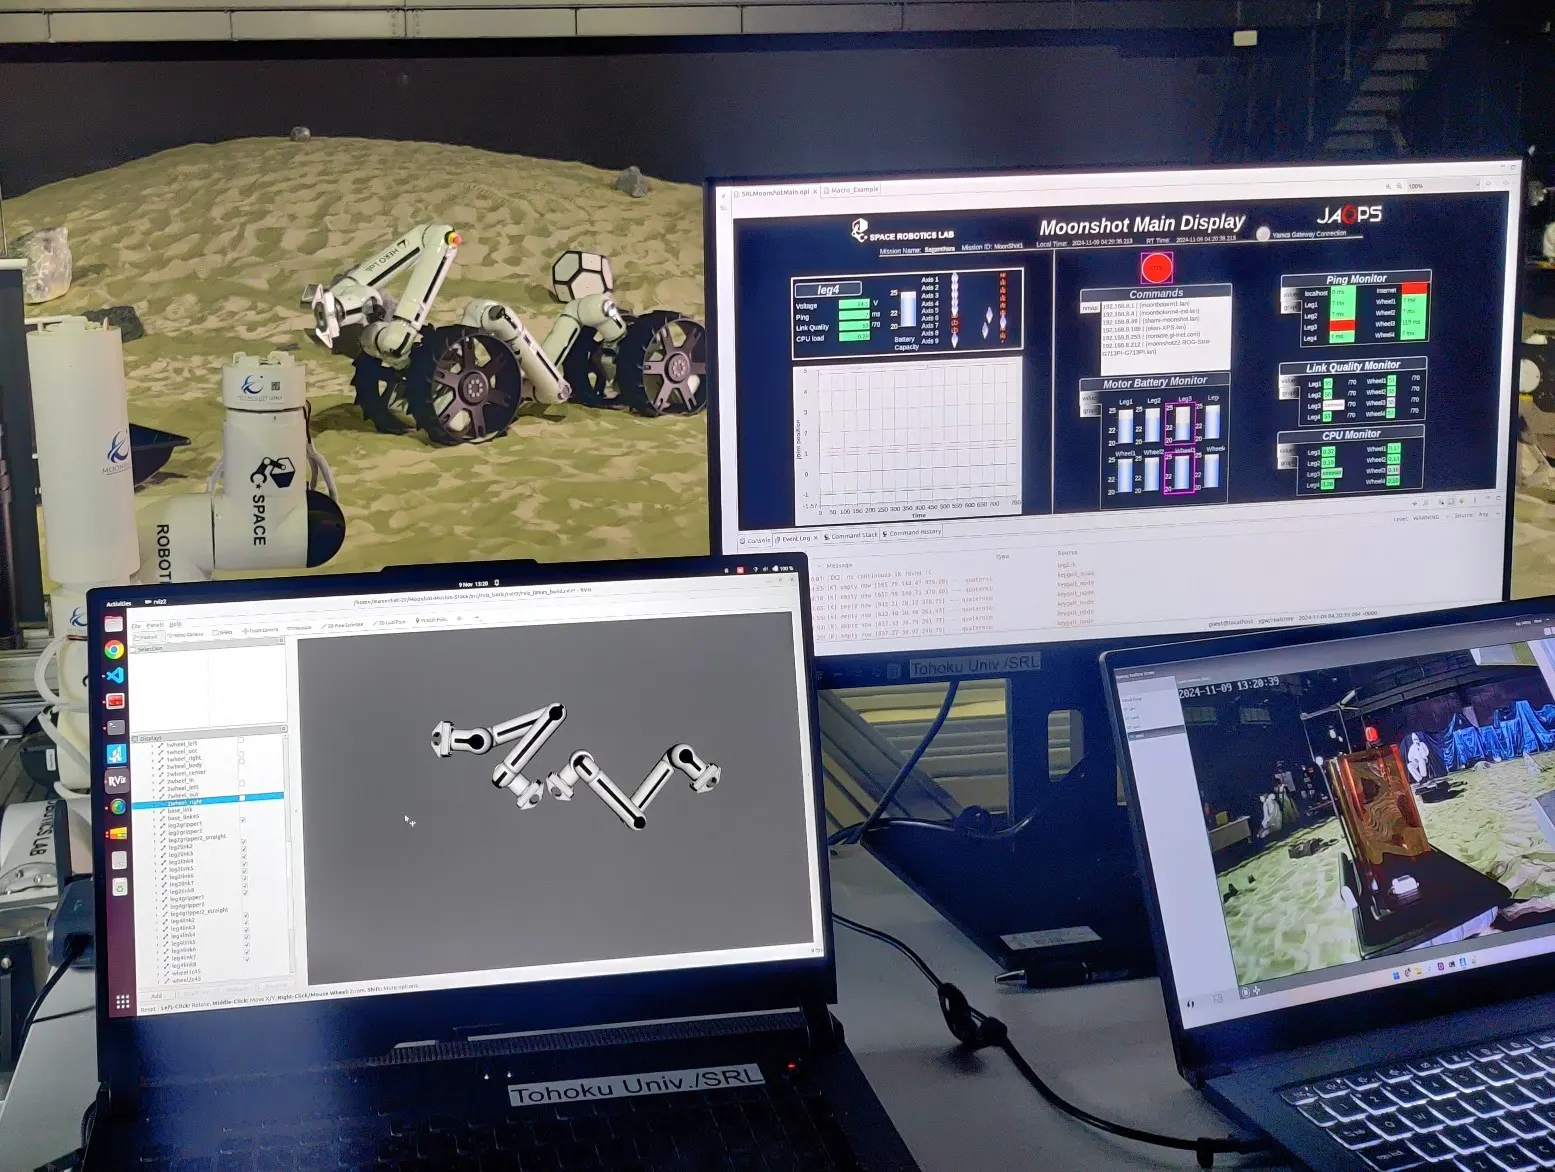
The IEEE T-FR article covers the design and development of the system and a preliminary field demonstration of milestone tasks that simulate setting up lunar infrastructure: civil engineering operations, transporting and deploying infrastructure components, and assisting with inflatable modules. It closes with the lessons learned during testing, with a focus on connector design.
My part was the control and learning side: decentralized control and reinforcement learning for a robot whose body changes every time a module is attached or removed, and the software that lets the modules work as one machine.
Best Paper Award in Planetary Robotics, IEEE iSpaRo 2025, Sendai, Japan
IEEE International Conference on Space Robotics (iSpaRo), 2025
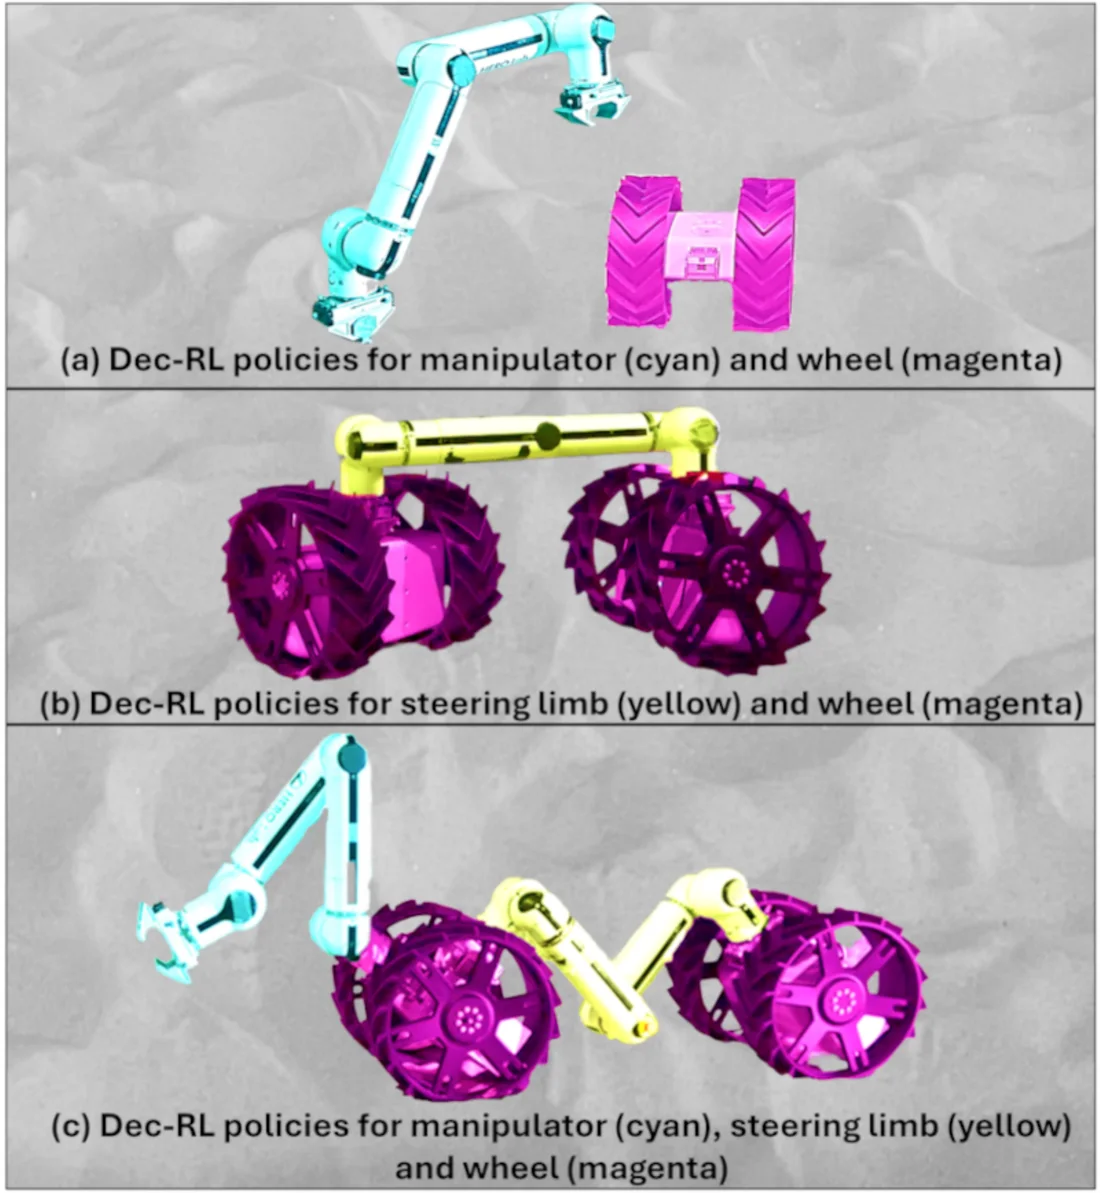
A decentralized reinforcement learning approach for robots whose morphology changes: each module learns to act on local, multi-modal observation rather than from a central controller, so the same policy set survives reconfiguration.
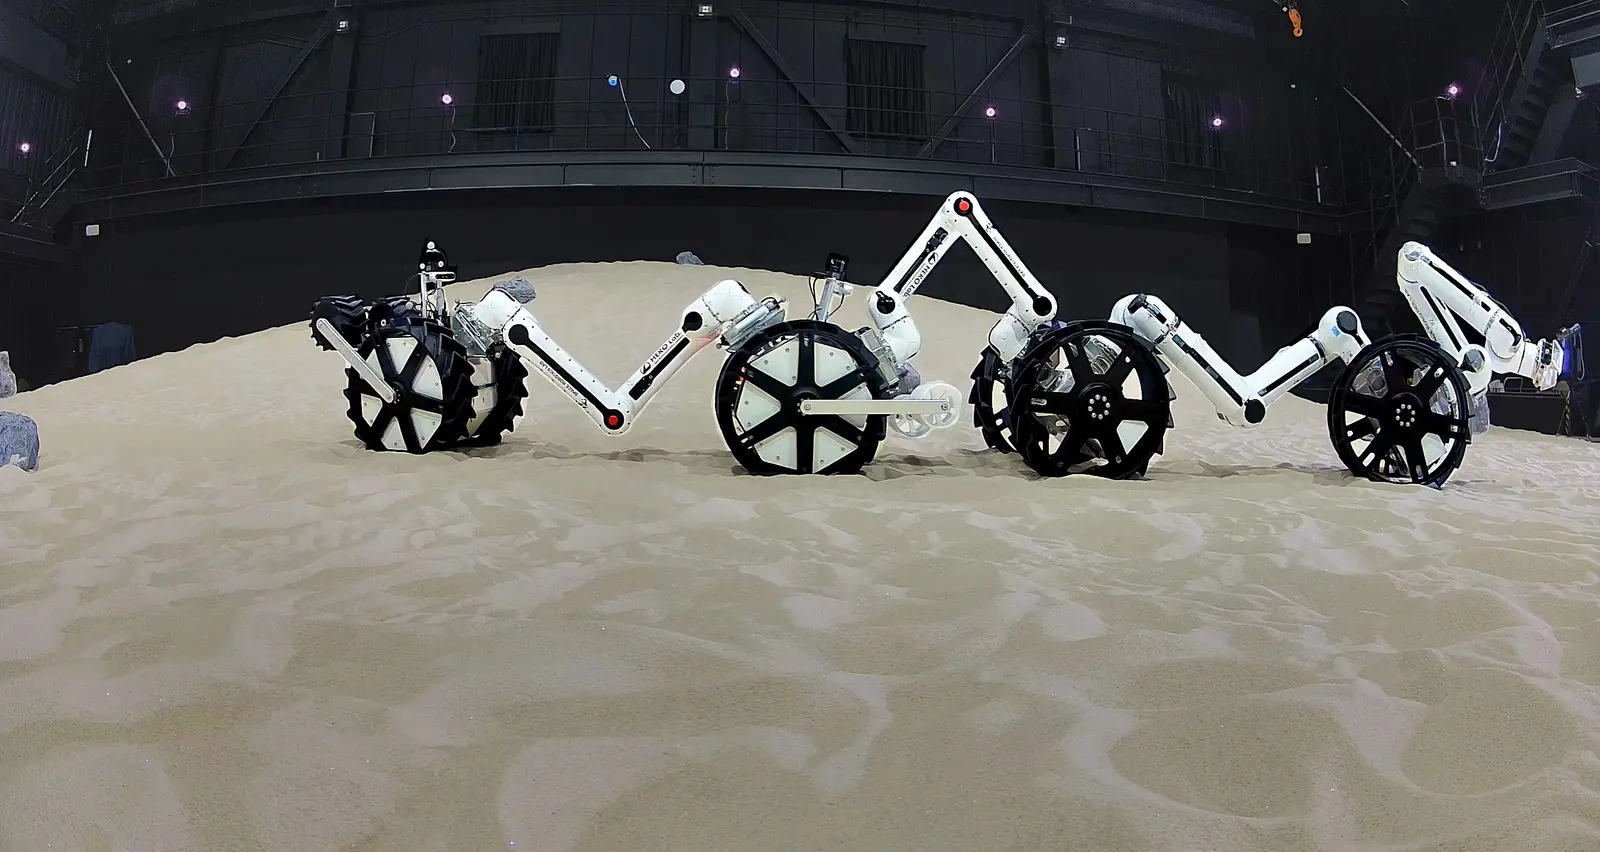
Field tested at
IEEE Transactions on Field Robotics (T-FR)
doi:10.1109/TFR.2025.3624346arXiv preprint
* Equal authorship.
IEEE International Conference on Space Robotics (iSpaRo)
doi:10.1109/ISPARO66239.2025.11436148arXiv preprintVideo
Best Paper Award in Planetary Robotics, IEEE iSpaRo 2025, Sendai, Japan
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
doi:10.1109/IROS60139.2025.11246735arXiv preprintVideoCode: Motion Stack
IEEE International Conference on Space Robotics (iSpaRo)
IEEE International Conference on Space Robotics (iSpaRo)
IEEE International Conference on Space Robotics (iSpaRo)
arXiv preprintVideoAccepted, to appear
* Equal authorship.
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
arXiv preprintAccepted, to appear
IEEE Access
In submission
* Equal authorship.
IEEE Robotics and Automation Letters (RA-L)
Demo videoIn submission