Plug and Play Modular Sensor Box
A modular sensor package for the MoonBot platform, fusing LiDAR, fisheye and depth cameras. Field tested by mapping a cave.
- Dates
- September 2025 to October 2025
- Field site
- Abukuma Cave, Japan
- Stack
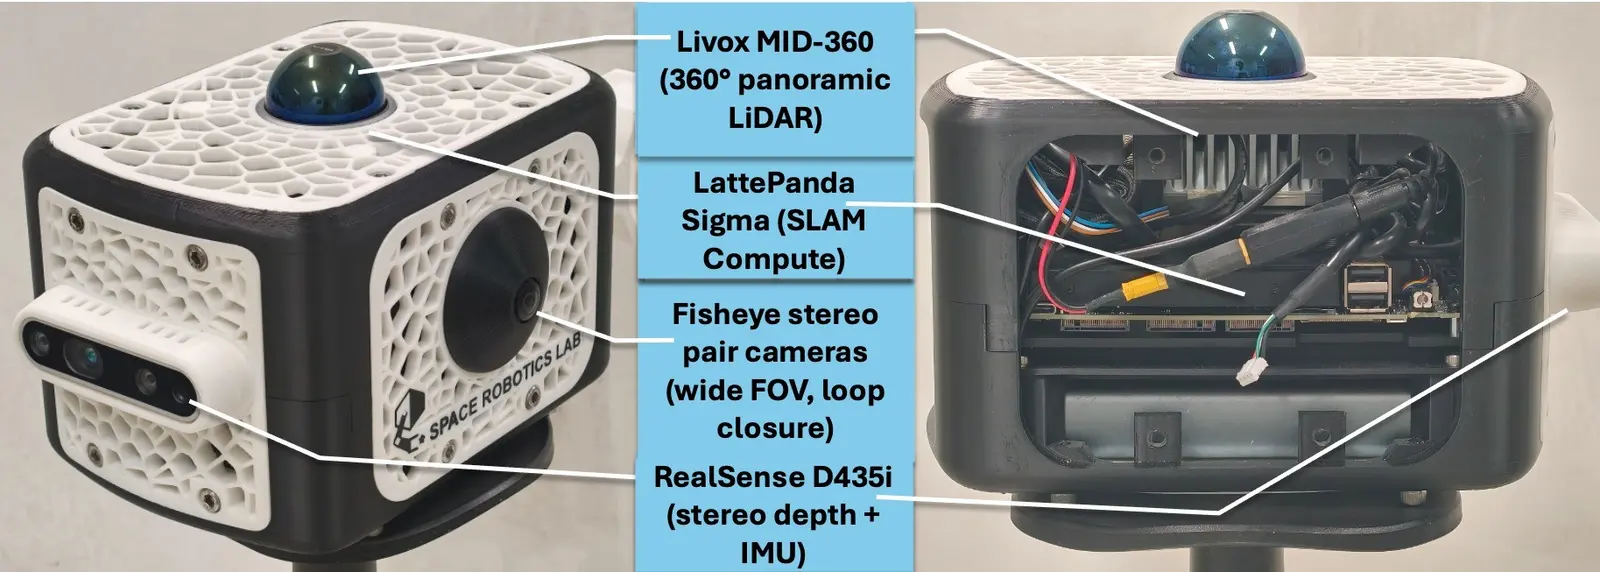
- Livox Mid-360 LiDAR, Intel RealSense D435i, Sensor fusion, SLAM, ROS 2
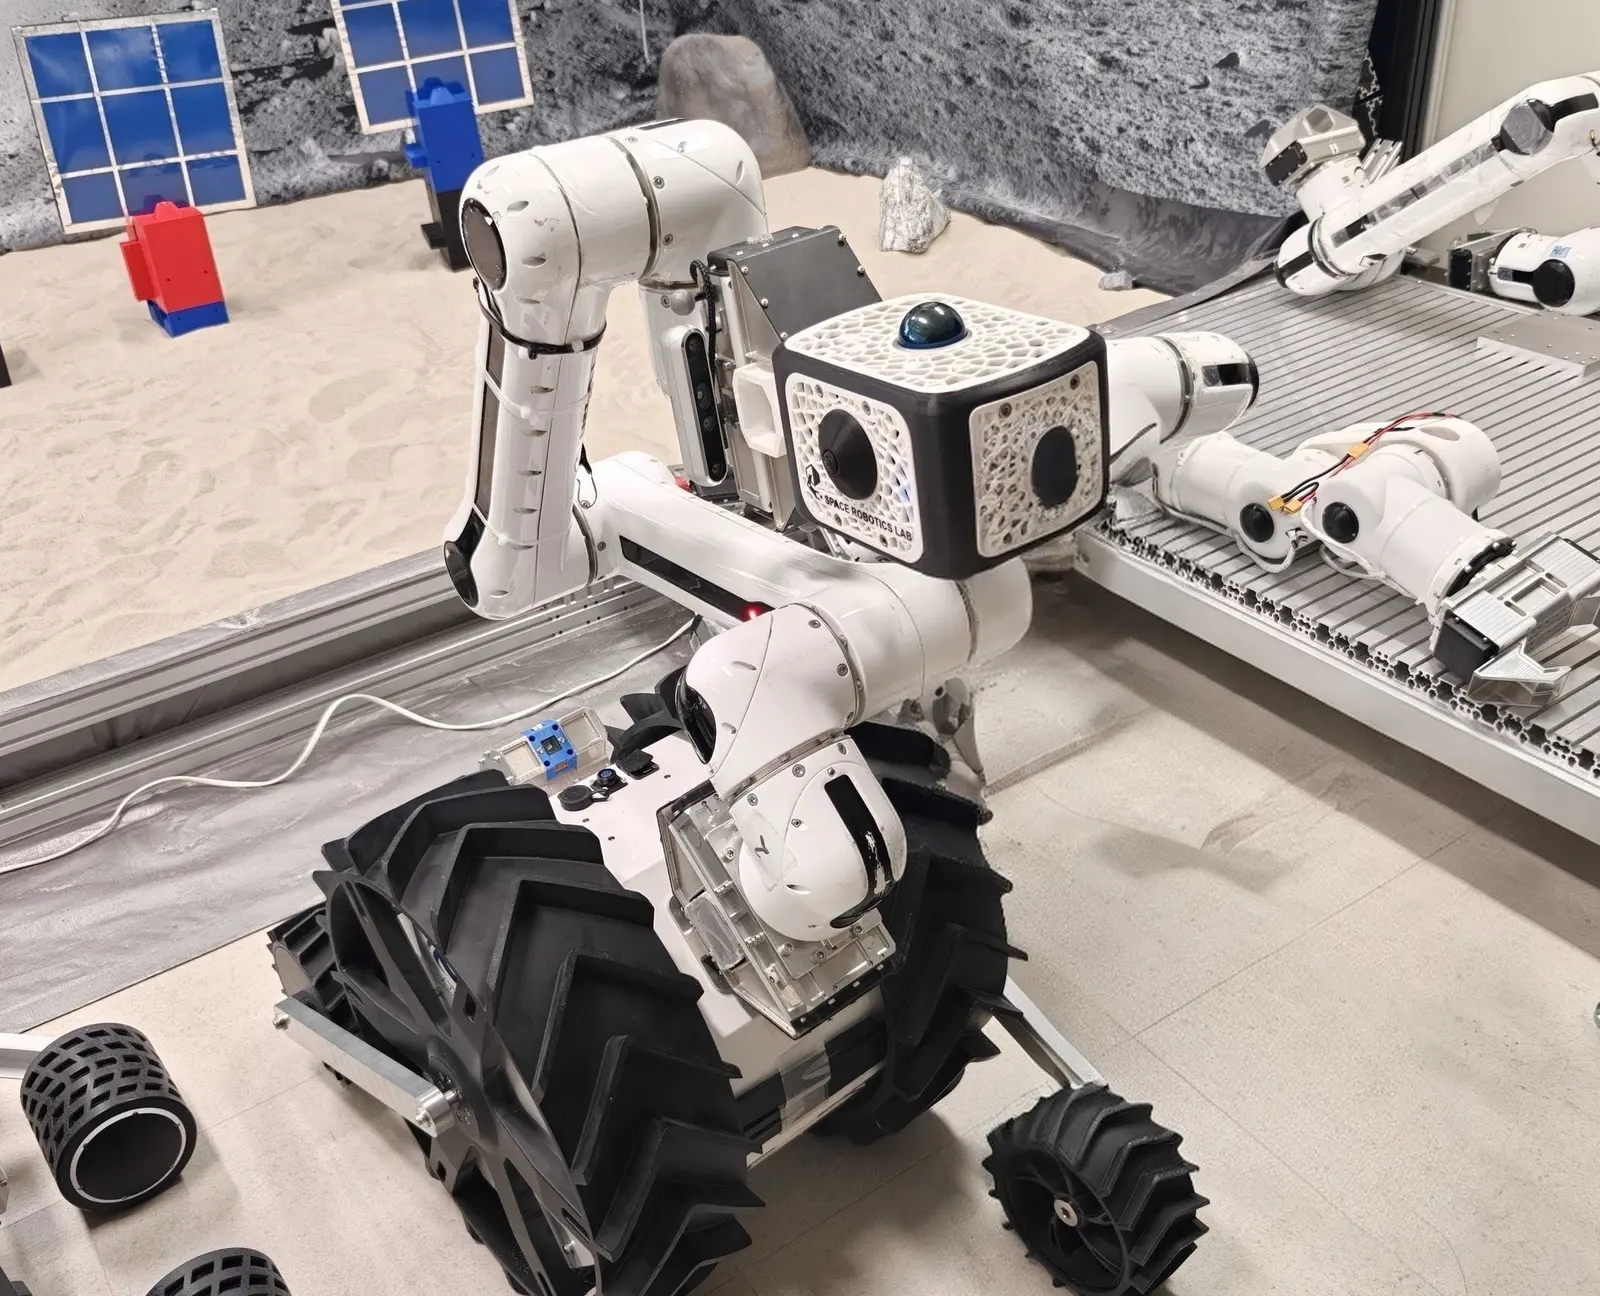
A plug-and-play sensor box for the MoonBot platform, fusing a Livox Mid-360 LiDAR, two fisheye cameras and an Intel RealSense D435i. Because the platform is modular, the sensing had to be modular too: any configuration should be able to take the box and get a usable picture of its surroundings.
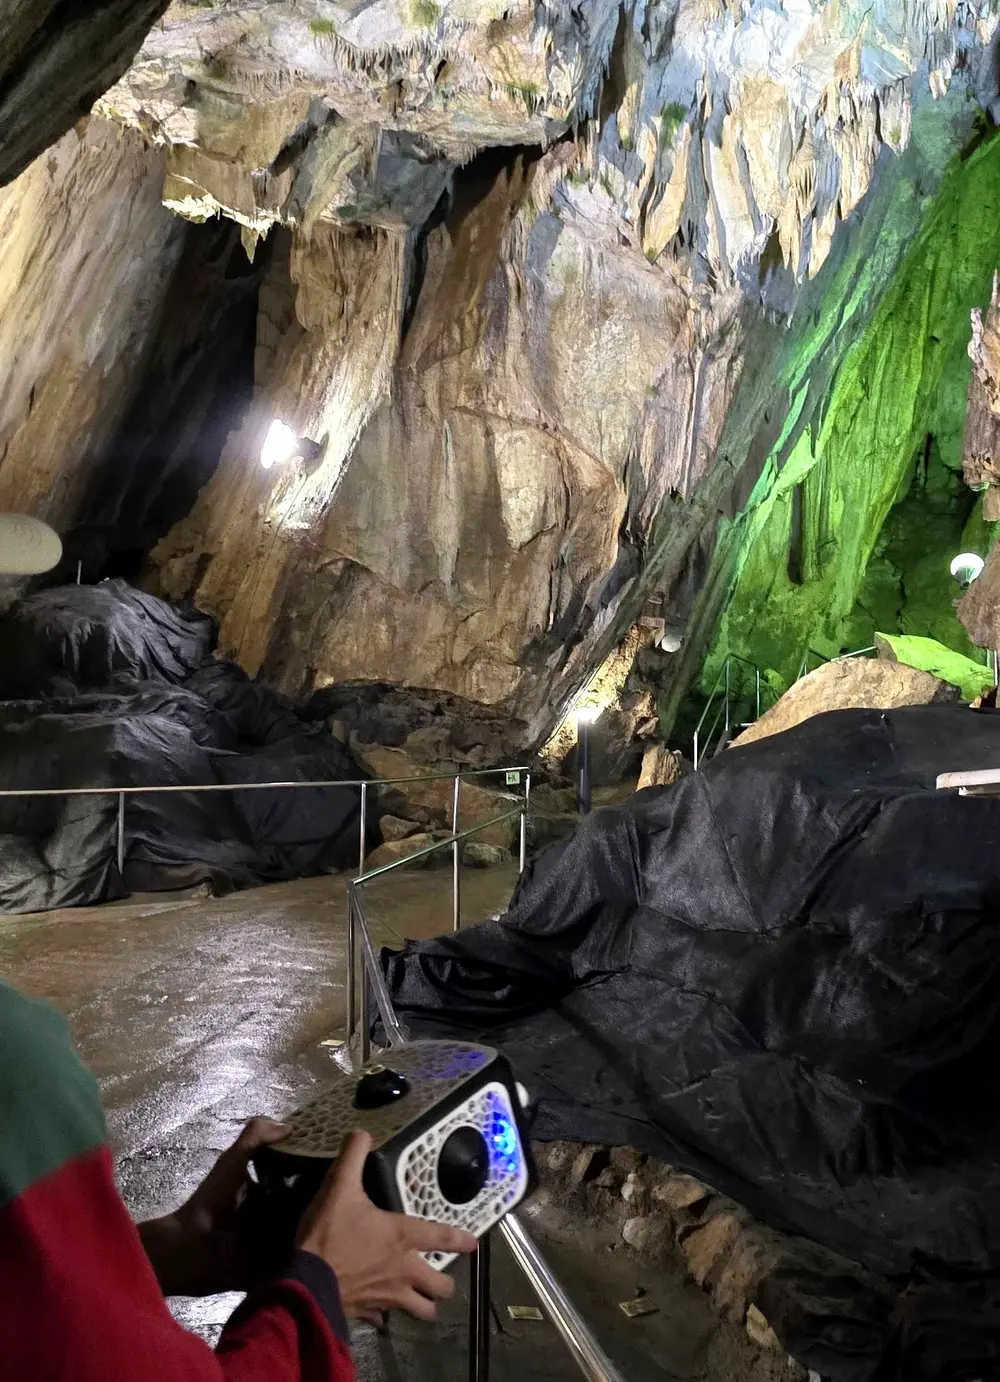
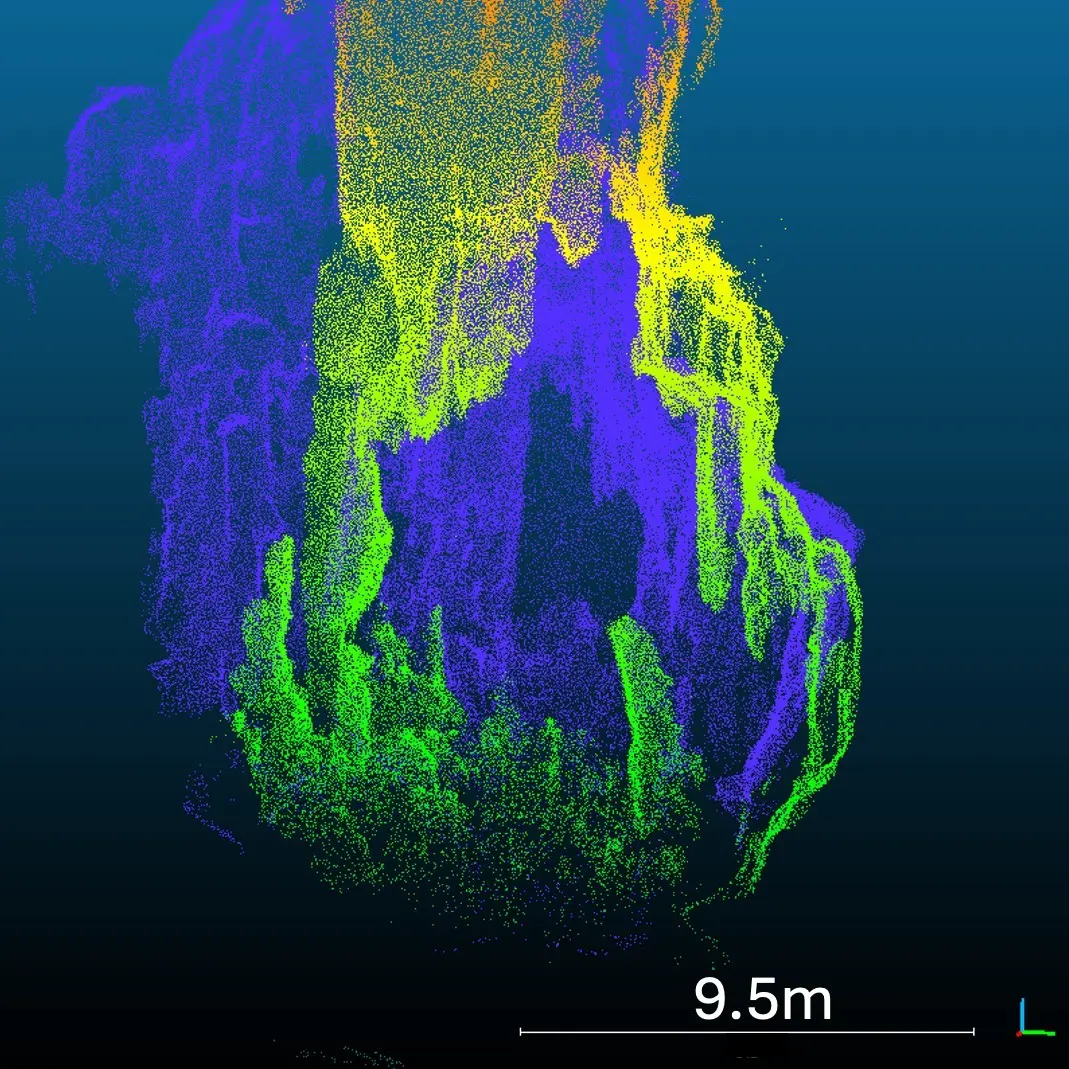
It was field tested by mapping Abukuma Cave, used here as a stand-in for lunar cave environments. Caves are a plausible location for lunar habitation and a genuinely hard sensing problem: no GNSS, no ambient light, and geometry that defeats assumptions built on open terrain.
Research direction
Modular reconfigurable lunar robots
MoonBot: one set of limbs, wheels and tools that reconfigures on demand into whichever machine a lunar construction task needs.