MoonBot: Modular and On-Demand Reconfigurable Robot Toward Moon Base Construction
IEEE Transactions on Field Robotics (T-FR)
doi:10.1109/TFR.2025.3624346arXiv preprint
* Equal authorship.
The JST Moonshot Goal 3 programme behind MoonBot: robot systems that can build and maintain a lunar outpost with minimal human help.
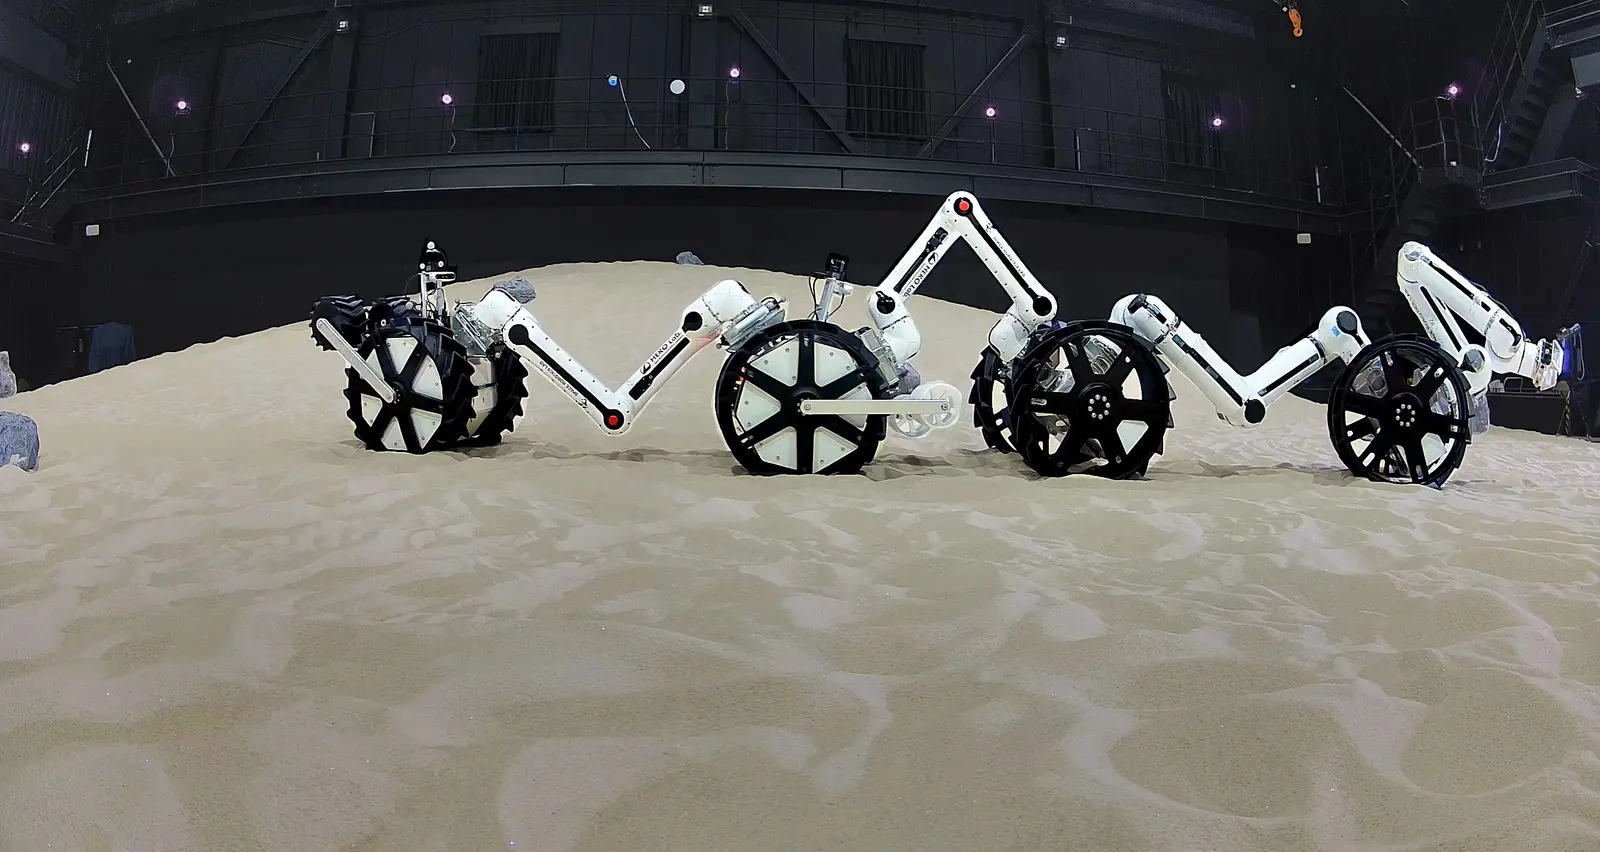
The umbrella programme behind most of my doctoral work. The goal set by JST Moonshot Goal 3 is a robot system that can build and maintain a lunar outpost with minimal human intervention, which means the system has to keep working when its own configuration, the terrain, and the task all change.
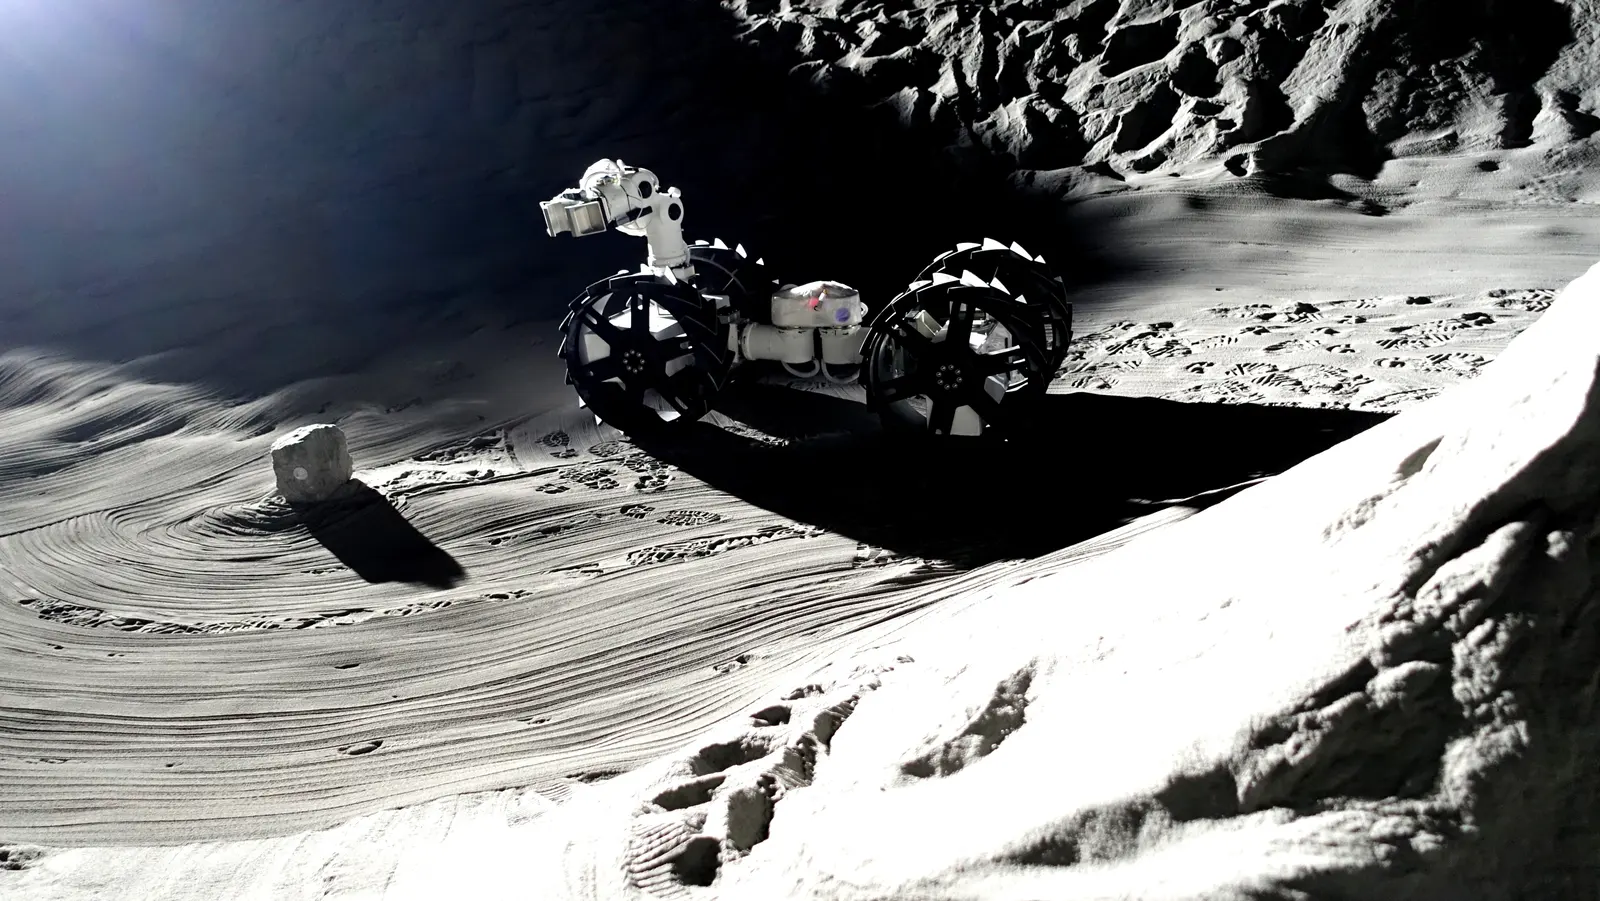
My part of it concentrated on the control and learning side: how a robot whose body can be rebuilt from modules learns policies that survive that rebuild, and how those policies transfer from simulation onto hardware that has to operate in lunar-analogue terrain and lighting.
IEEE Transactions on Field Robotics (T-FR)
doi:10.1109/TFR.2025.3624346arXiv preprint
* Equal authorship.
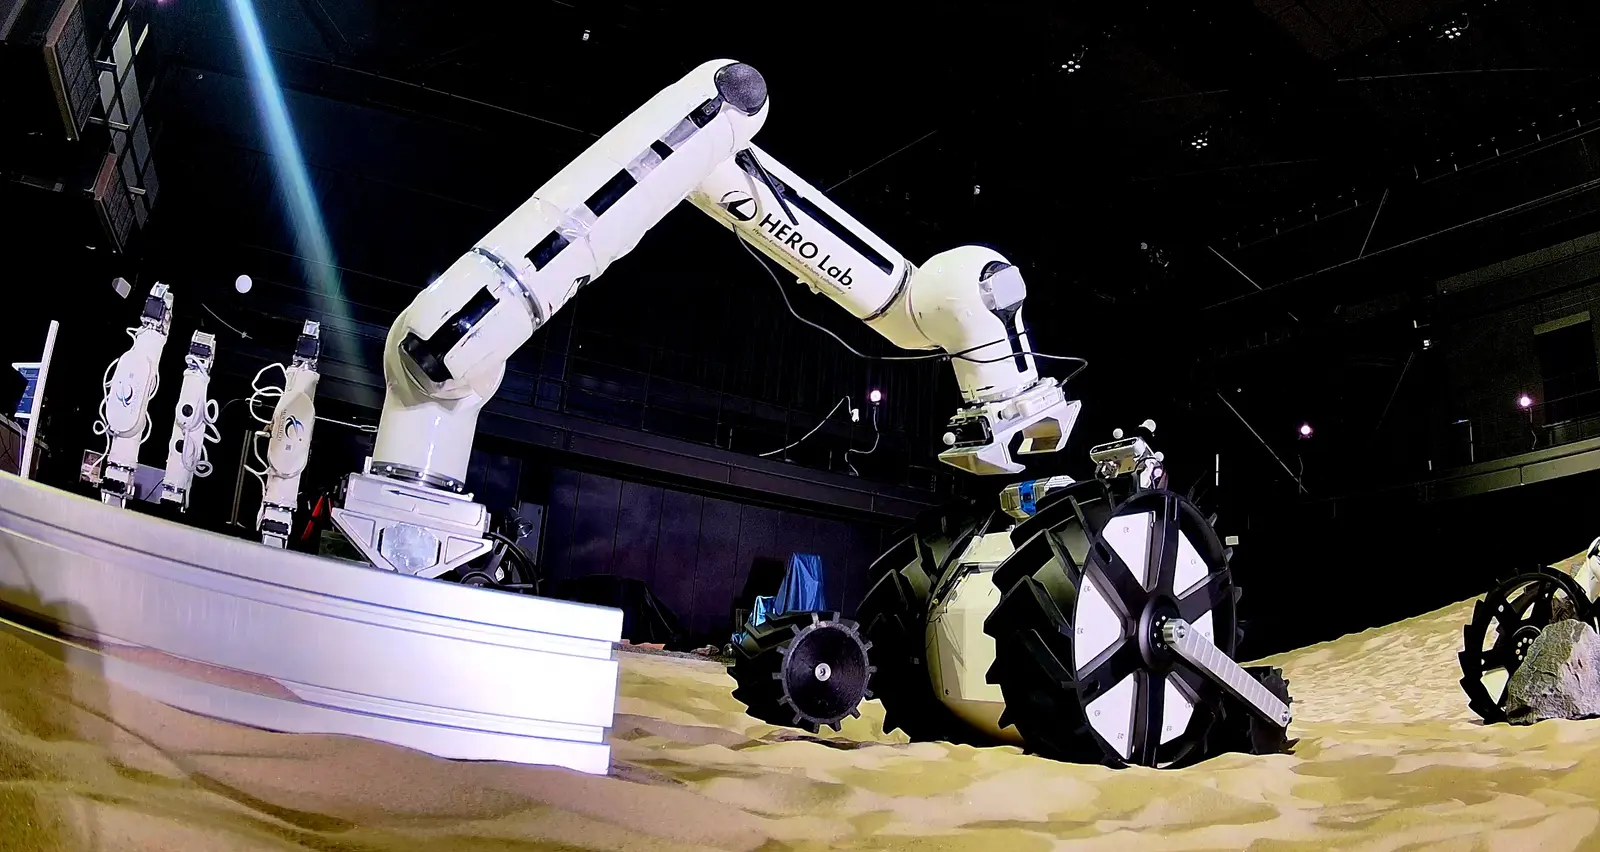
MoonBot: one set of limbs, wheels and tools that reconfigures on demand into whichever machine a lunar construction task needs.
Decentralized RL, agentic planning, and the sim-to-real gap that decides whether any of it survives contact.