Ashutosh Mishra

Research

Learning and autonomy for field robots

What has to be true for a learned policy to still work outside the simulator?

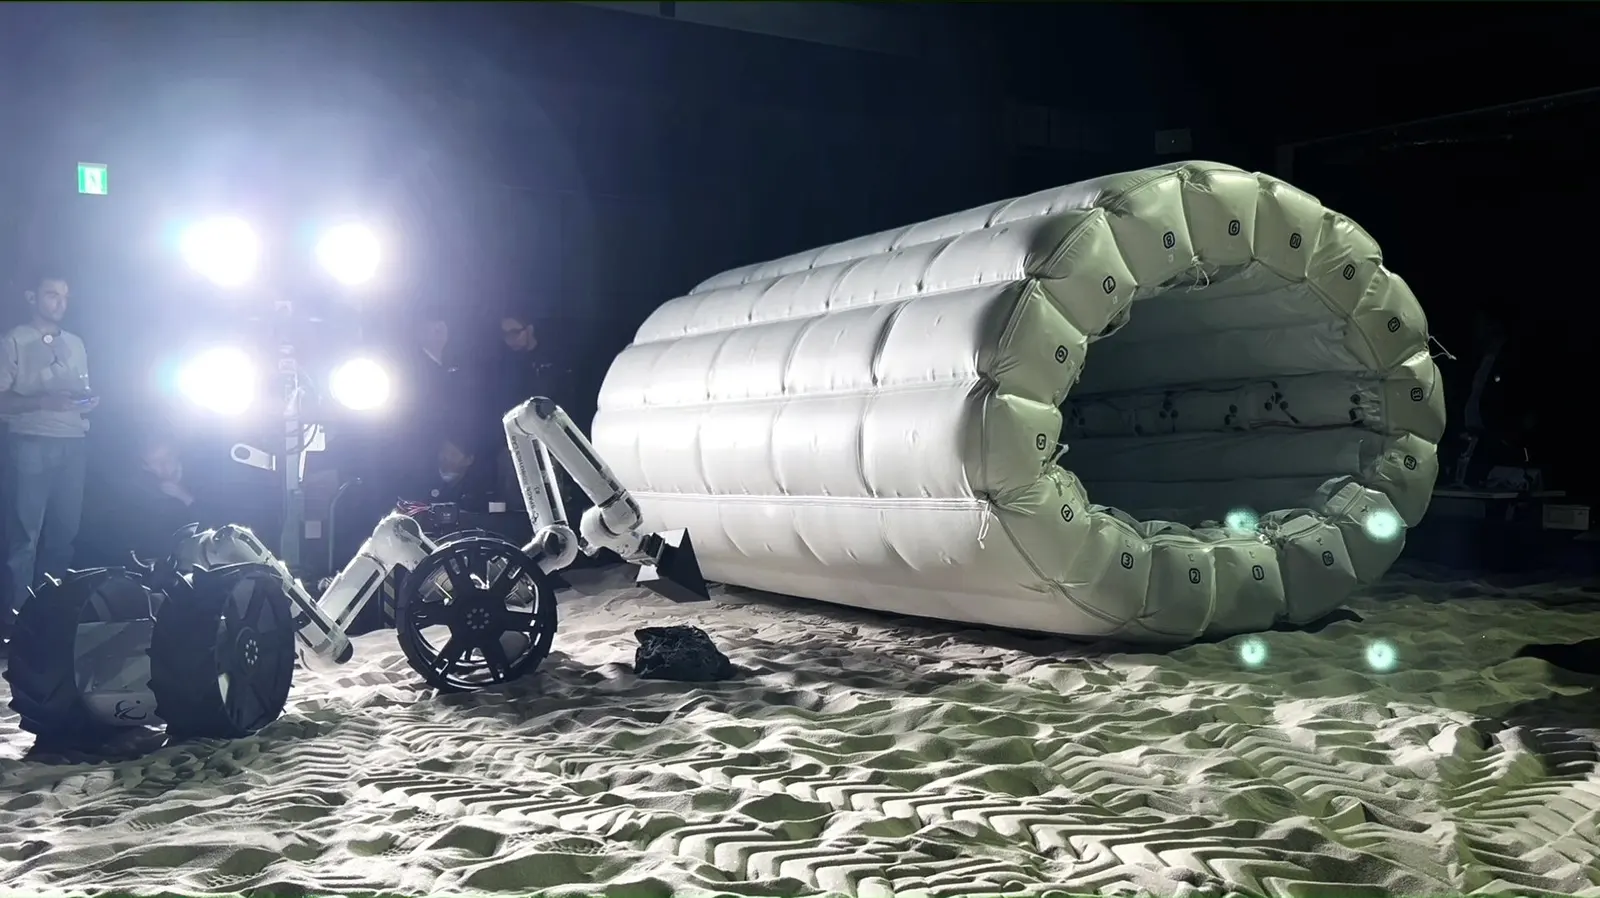
A MoonBot Dragon monitoring the HIDAS inflatable habitat module as it inflates, using a camera on its limb, JAXA Space Exploration Test Field.

A policy that performs well in simulation and fails on hardware has told you something about your simulator, not about your method. Field robotics is where that distinction stops being academic, and it is why the work below goes onto real hardware in lunar-analogue terrain wherever it can, rather than stopping at benchmark environments.

Two threads run through it. One is decentralization: when a robot's morphology can change, control that assumes a fixed body and a central authority breaks, so each module has to act on what it can observe locally. The other is agentic planning: giving a modular platform enough autonomy to decompose a task and execute it without a human specifying every step.

Field tested at

  • JAXA Space Exploration Test Field, Sagamihara

Projects in this direction

4

Publications in this direction

5
IEEE iSpaRo2025

Multi-Modal Decentralized Reinforcement Learning for Modular Reconfigurable Lunar Robots

Ashutosh Mishra, Shreya Santra, Elian Neppel, Edoardo M. Rossi Lombardi, Shamistan Karimov, Kentaro Uno, Kazuya Yoshida

IEEE International Conference on Space Robotics (iSpaRo)

A decentralized reinforcement learning approach for robots whose morphology changes: each module learns to act on local, multi-modal observation rather than from a central controller, so the same policy set survives reconfiguration.

Best Paper Award in Planetary Robotics, IEEE iSpaRo 2025, Sendai, Japan

IEEE/RSJ IROS2026

Distributed Multi Robot Lunar Cargo Transportation via Phase Decomposed Reinforcement Learning

Ashutosh Mishra, Elian Neppel, Shreya Santra, Antoine Jonquières, Muhammad Athallah Naufal, Kentaro Uno, Kazuya Yoshida

IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)

Lunar cargo transport split into lifting, transportation and placement, each learned as its own policy so several robots can share the load, evaluated in simulation and in field experiments at a JAXA test facility.