Enhancing Autonomous Manipulator Control with Human-in-loop for Uncertain Assembly Environments
IEEE International Conference on Automation Science and Engineering (CASE)
Human-in-the-loop verification of UR16e manipulator control for precise assembly under uncertain terrain and visual conditions.
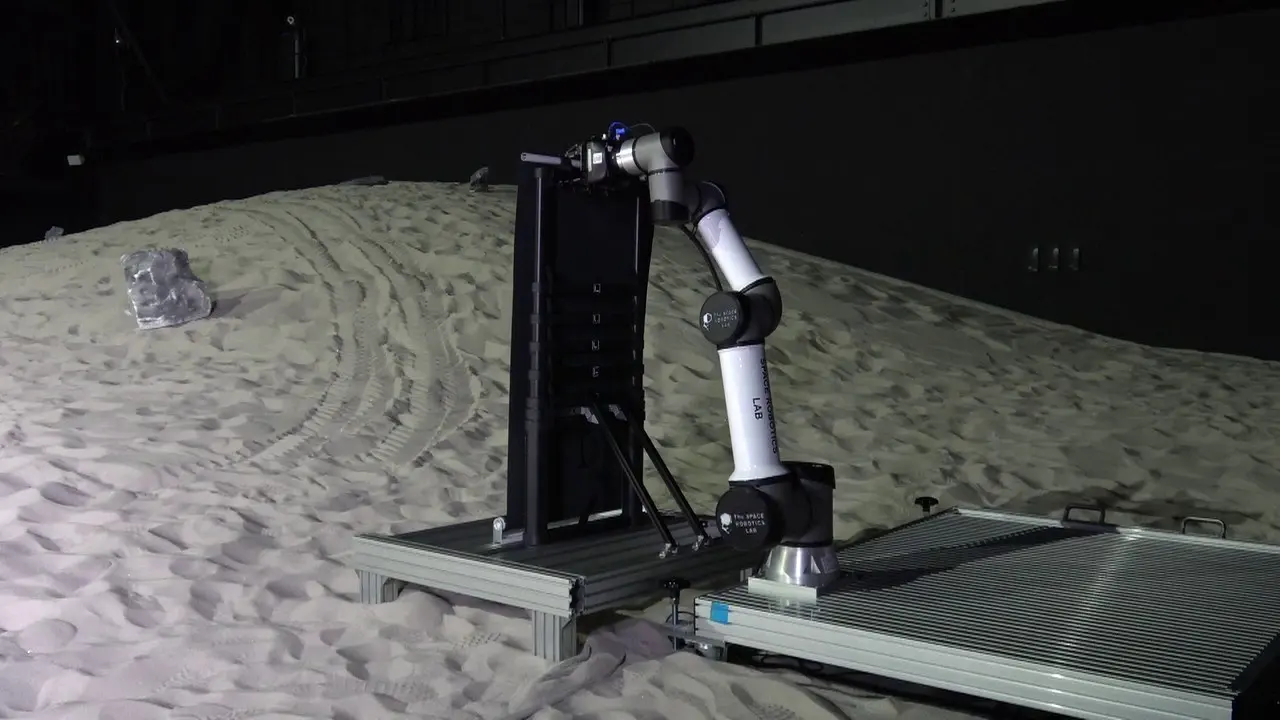
Deploying solar infrastructure on the lunar surface means precise assembly by a manipulator that cannot fully trust its own perception: the terrain is uneven, the lighting is directional and harsh, and there is no operator standing next to it.
This work performed human-in-the-loop verification and validation of UR16e manipulator control for those assembly and deployment tasks, using ArUco markers and OpenCV for pose estimation under exactly those uncertain visual conditions.
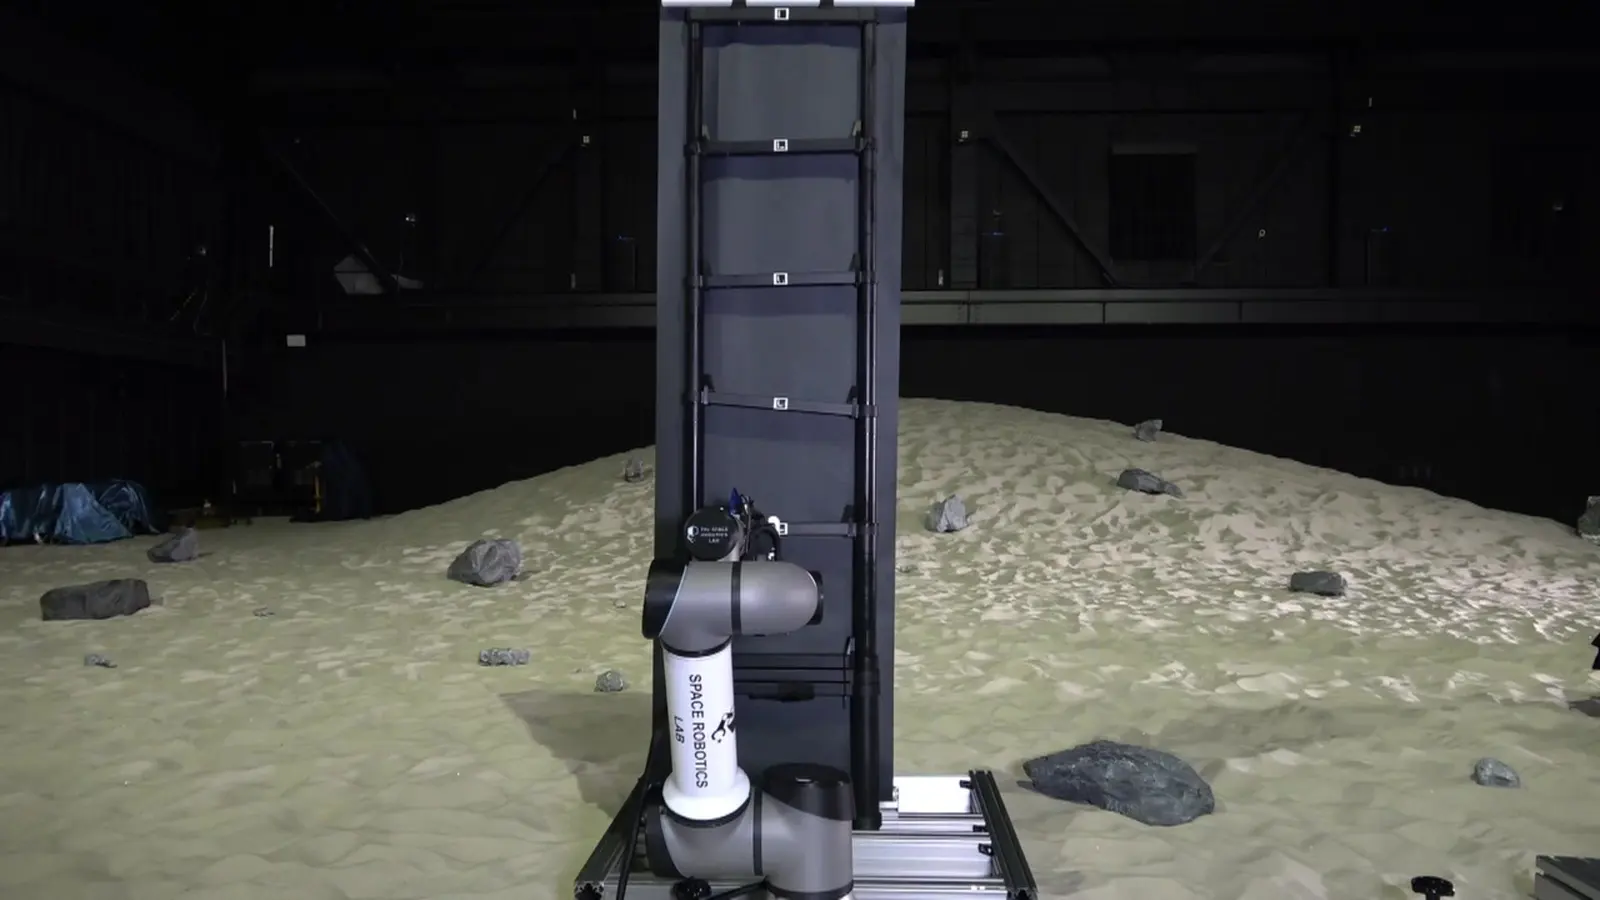
IEEE International Conference on Automation Science and Engineering (CASE)
Decentralized RL, agentic planning, and the sim-to-real gap that decides whether any of it survives contact.