MoonBot APEX: Agentic Planning and Execution for Modular Lunar Robots
IEEE Robotics and Automation Letters (RA-L)
Demo videoIn submission
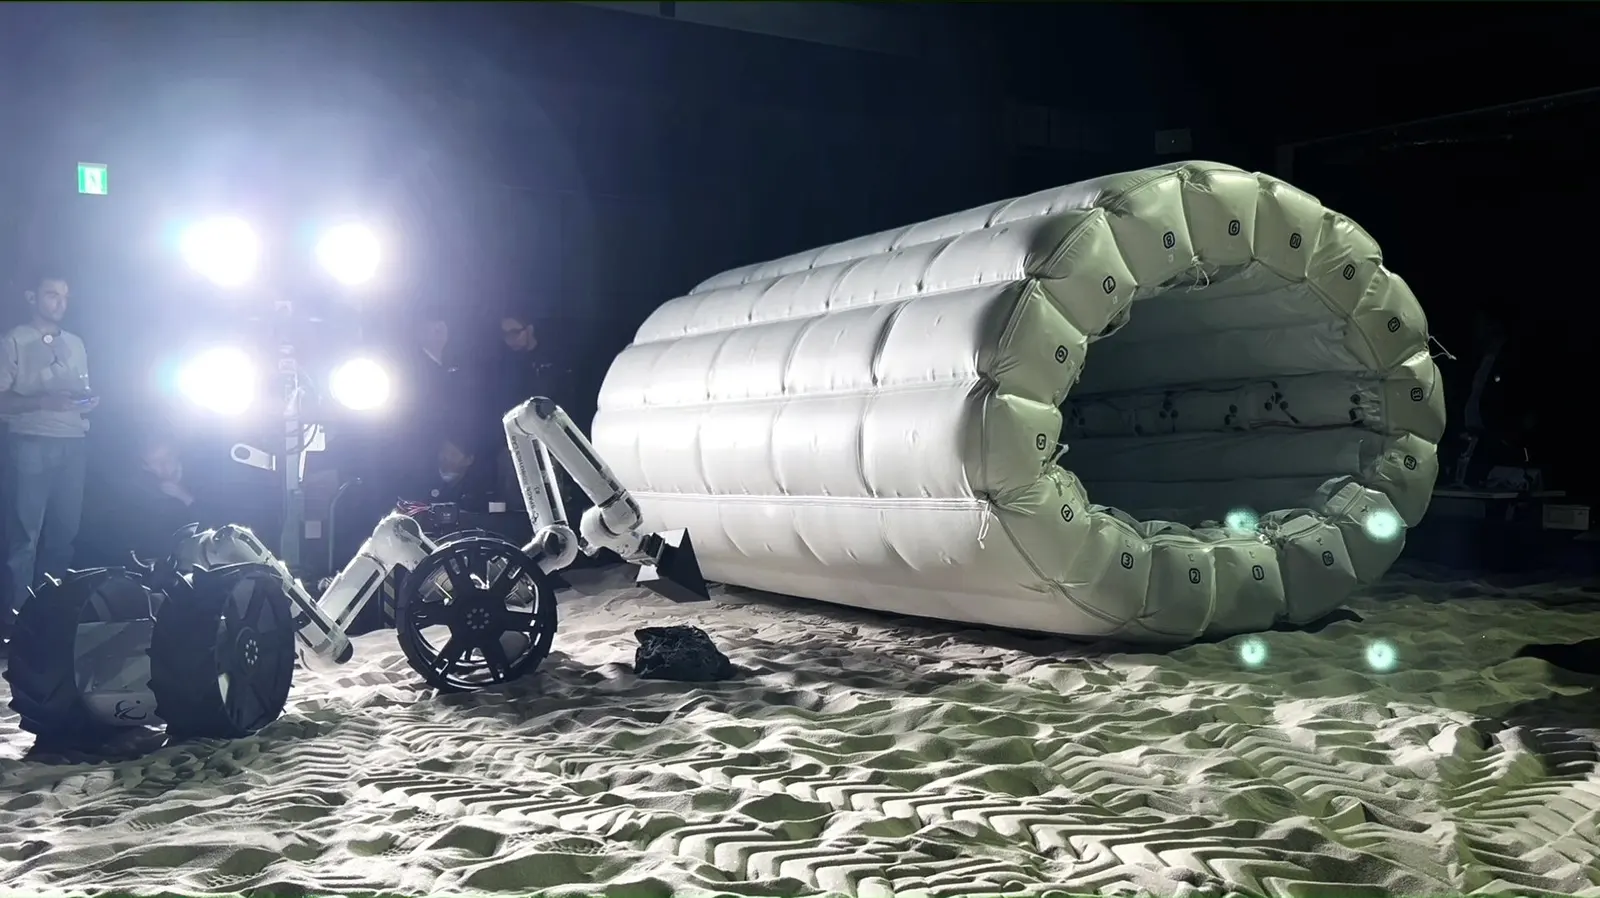
Full-scale field validation of agentic planning and execution for modular lunar robots, in lunar-analogue terrain and lighting.
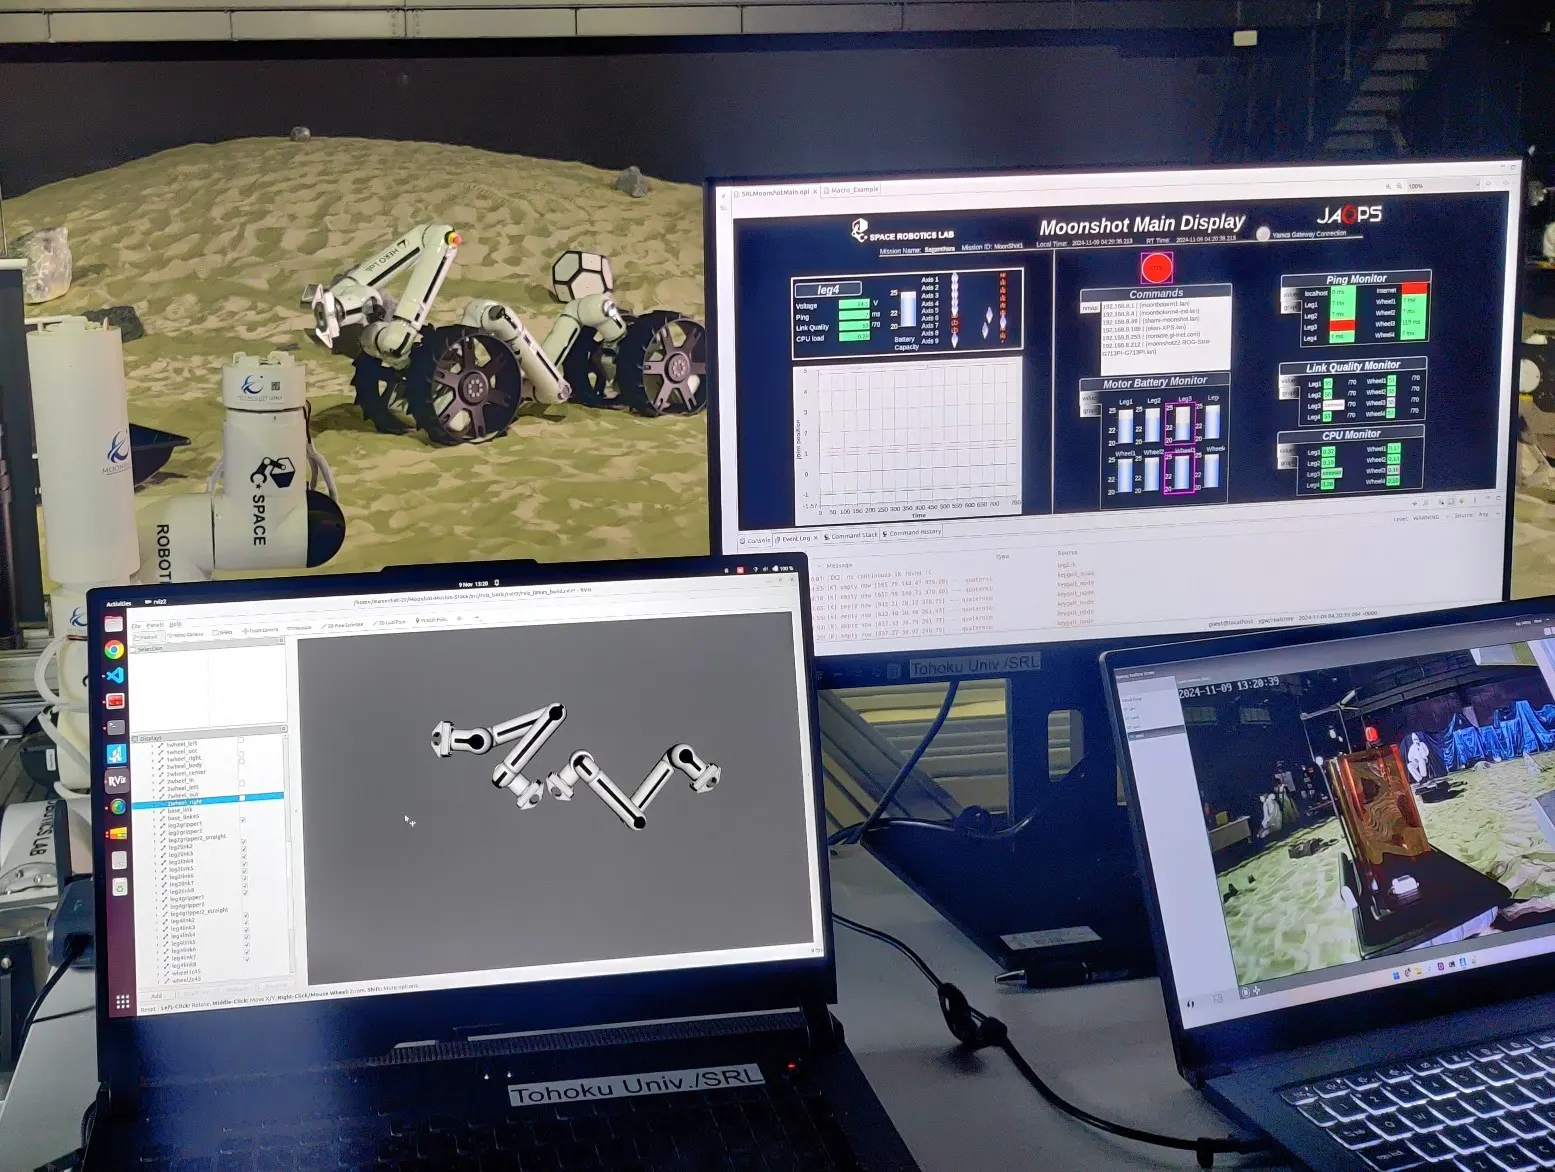
APEX asks whether a modular robot can be given a task rather than a script: decompose the goal, decide which configuration it needs, and execute without a human specifying every intermediate step.
The framework was validated at full scale at the JAXA Space Exploration Test Field in Sagamihara, in terrain and lighting chosen to approximate lunar conditions. Field validation is the part that matters here, because agentic planning that works in simulation and fails on regolith has told you about your simulator.
IEEE Robotics and Automation Letters (RA-L)
Demo videoIn submission
Decentralized RL, agentic planning, and the sim-to-real gap that decides whether any of it survives contact.