Ashutosh Mishra

Projects

Modular RL Policy Implementation on Reconfigurable Robots

Reinforcement learning control policies tested on morphology-varying modular robots across multiple reconfigurations.

Dates
February 2025 to March 2025
Field site
JAXA Space Exploration Test Field, Sagamihara
Stack
Reinforcement learning, Isaac Lab, PyTorch, Modular robotics
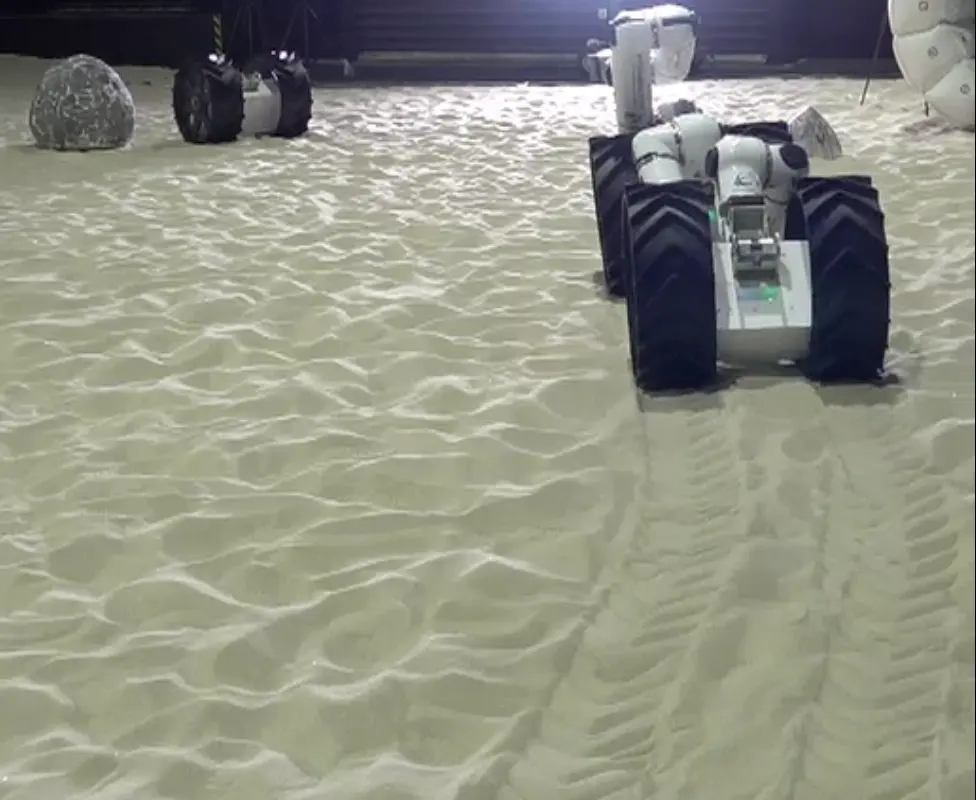
Phase 1 of the field trial: MoonBot detecting its target and driving to it under learned locomotion and steering policies, JAXA Space Exploration Test Field.

A controller written for one fixed body does not transfer when the body changes. This campaign tested reinforcement learning policies on robots whose morphology varied between runs, to see whether adaptive control held up across reconfigurations rather than only on the configuration it was trained for.

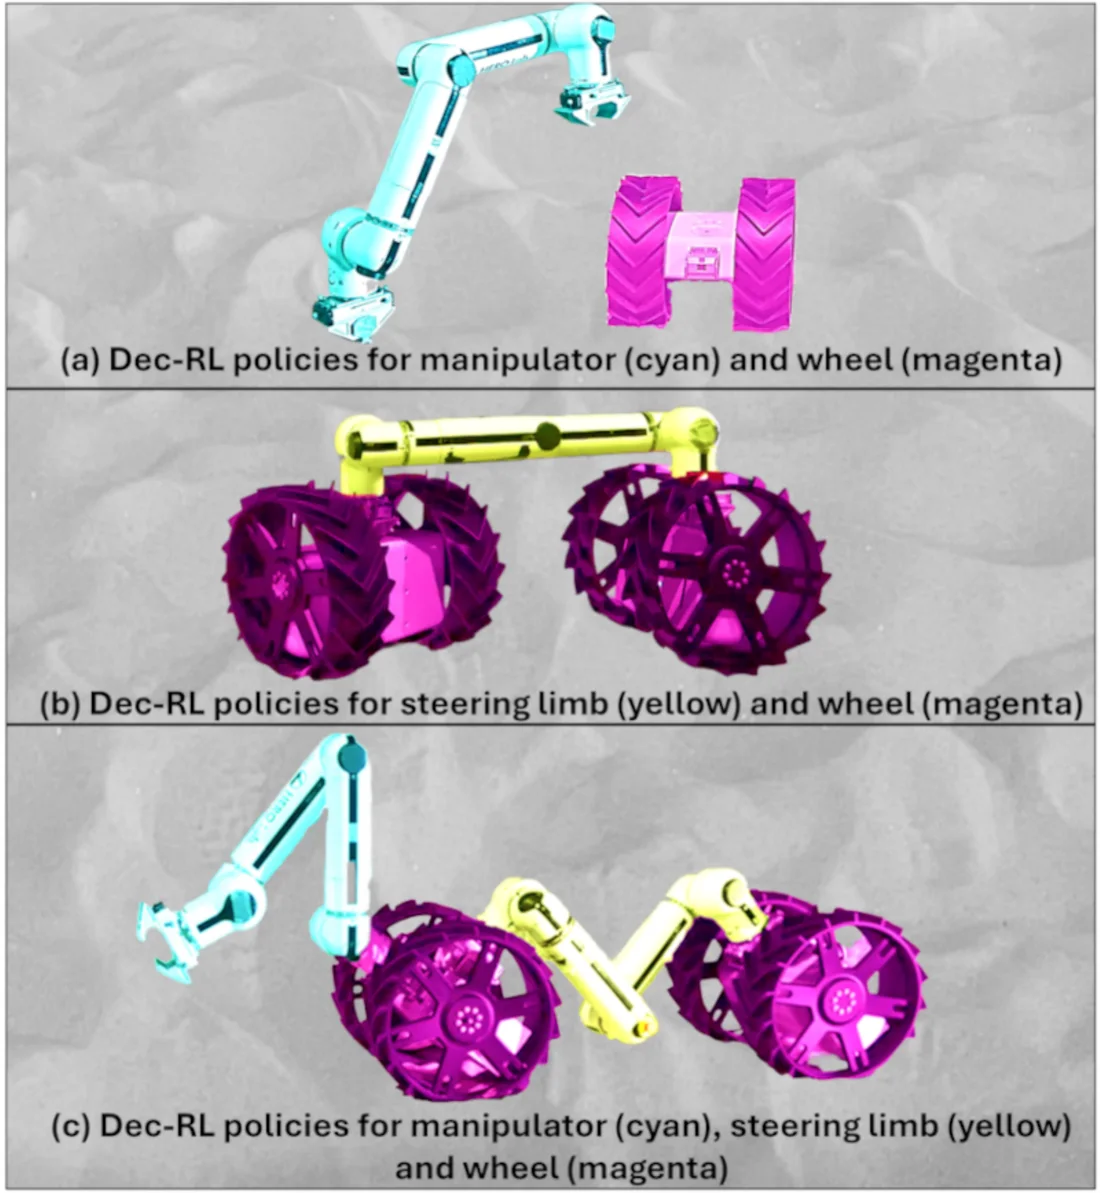
The result fed directly into the decentralized approach in the iSpaRo 2025 paper: each module acting on local observation rather than waiting on a central controller that assumes it knows the whole body.

Figure 1 of the iSpaRo 2025 paper: each module coloured by the policy that drives it.

Publications from this work

Research direction